
Robot Loading a Bowl Sanding Machine: What Must Be Solved First?
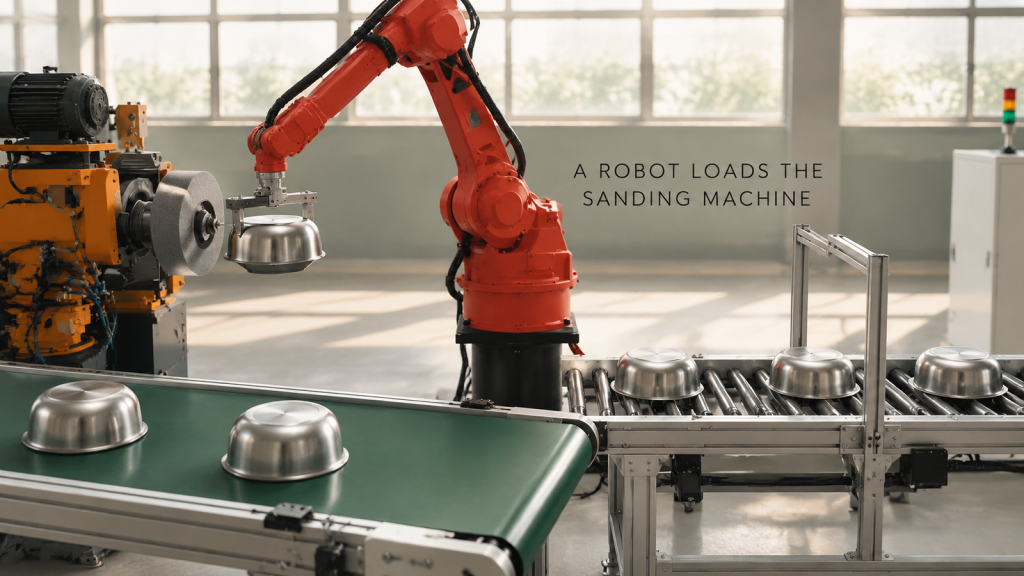
Robot loading for a stainless bowl sanding machine: gripper handoff, centring on the chuck, dust protection and a layout that keeps the machine busy.
Robot Welding a Steel Tube Frame: What Makes It Work in One Cell?
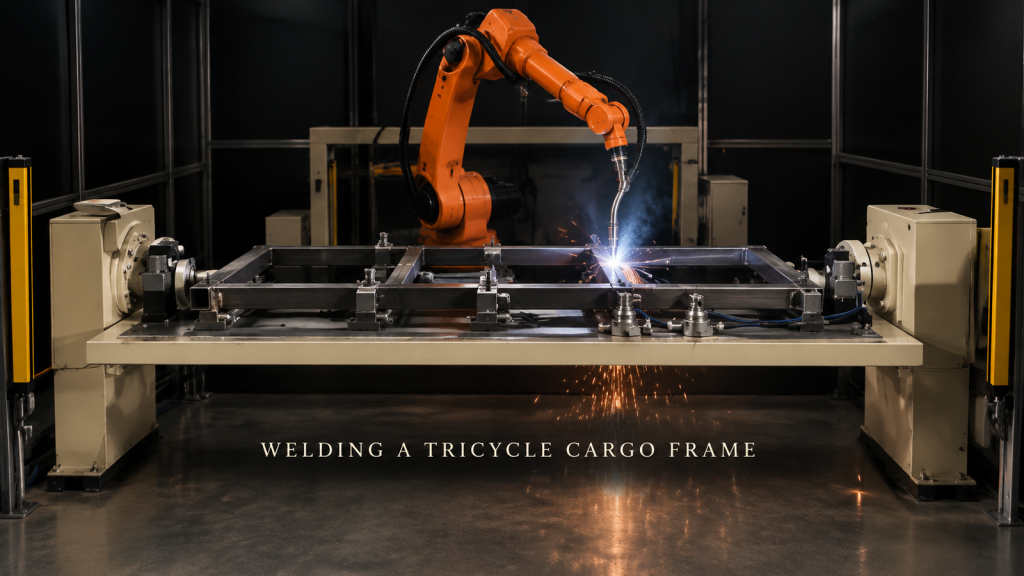
What makes a steel tube frame weldable by one robot: tube locating, joint order against distortion, underside welds and light curtains.
Robot Welding a Sheet-Metal Filter Housing: What Allows One Clamping?
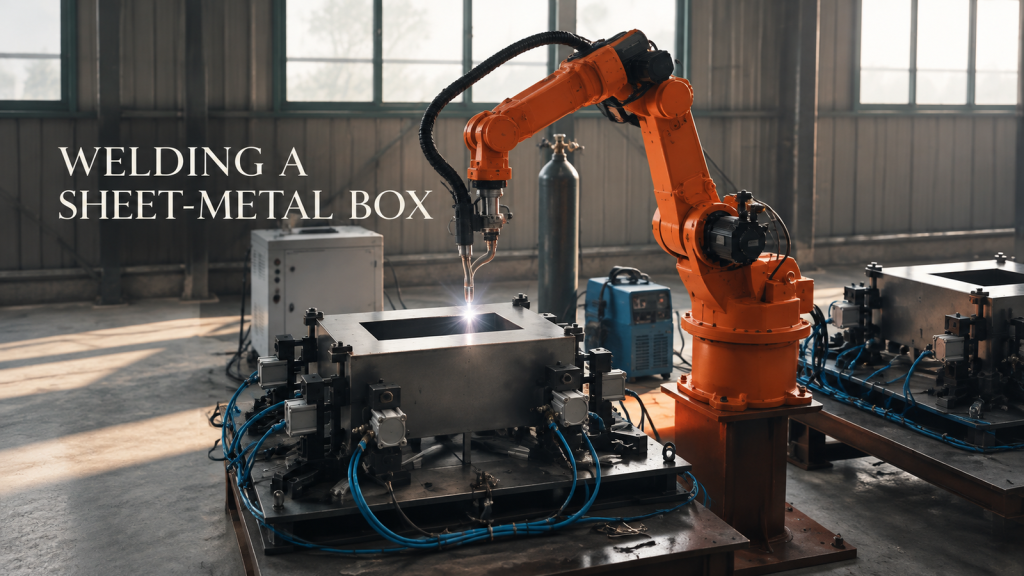
How clamp layout, torch angle changes and weld order decide whether a sheet-metal box can be robot-welded in one clamping, and what to send for a quote.
Palletizing Packed Cartons with a Four-Axis Robot: What Keeps an End-of-Line Cell Stable?
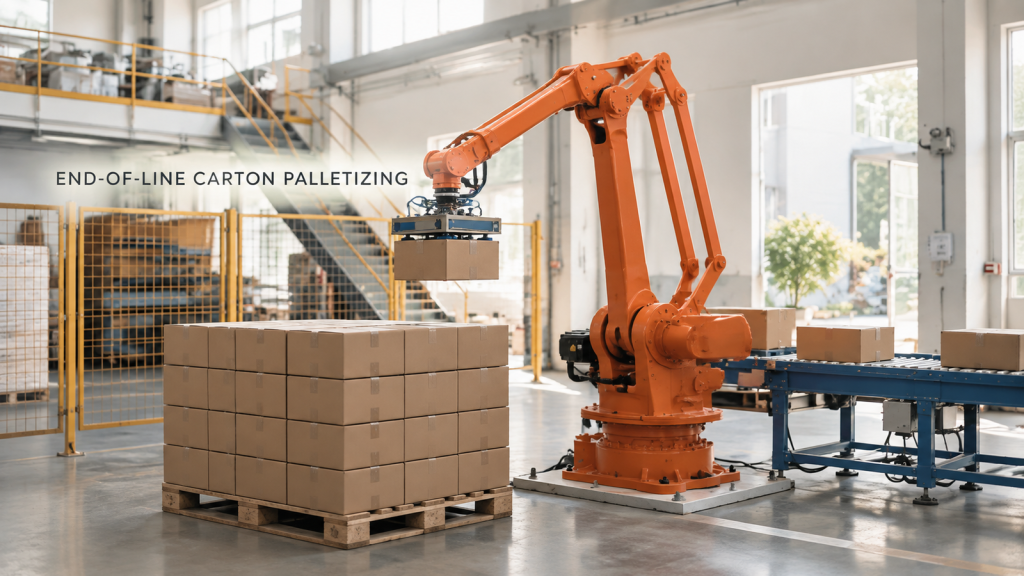
Four-axis robot carton palletizing: grip without crushing, a stable stacking pattern and a repeatable pick position at the conveyor end.
Robot Press Tending on a Wheel Rim Line: What Decides Whether It Can Be Handed Over?
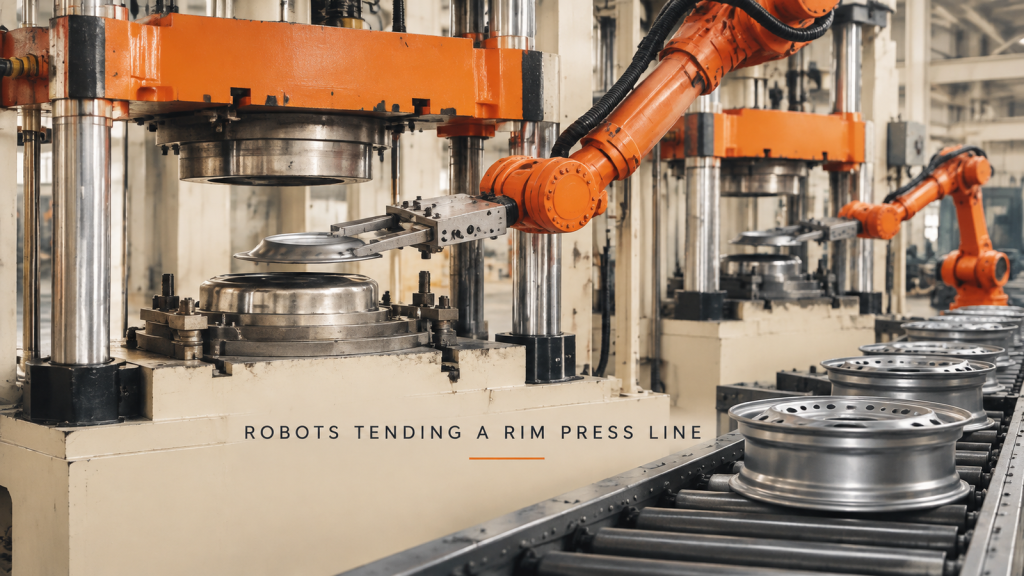
Robot press tending on a wheel rim line: carrying the part into the die, the robot-press interlock, part location, and scaling from one press to a row.
Loading Yarn Bobbins onto a Creel with a Cobot: What Does the Cell Have to Get Right?
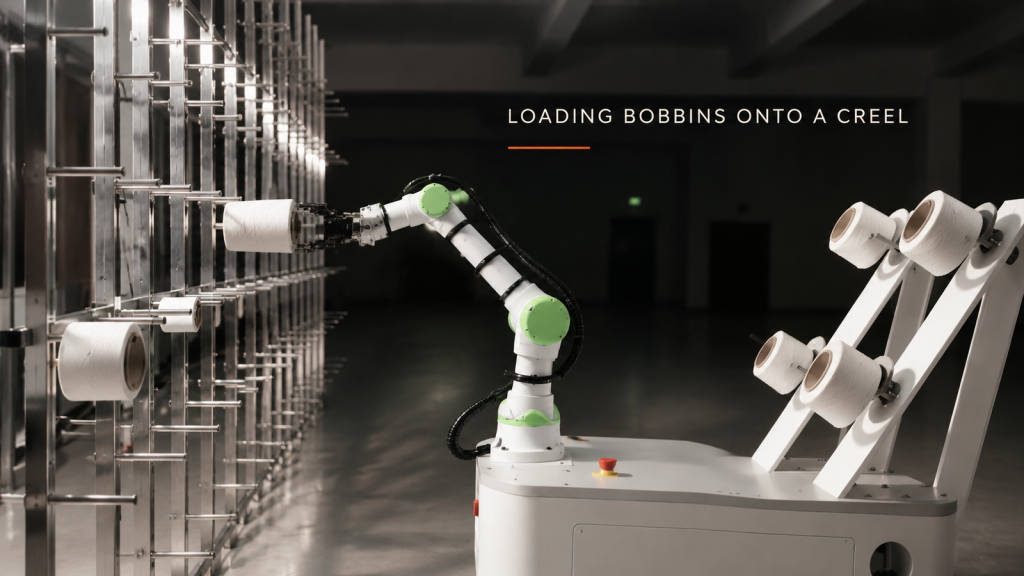
Loading yarn bobbins onto a creel with a cobot: grip clear of the yarn, bore-to-peg alignment, reach to top and bottom pegs, and where a mobile base fits.
Robot Flame Cutting of Thick Steel Plate: When Can the Handheld Torch Move to a Robot?
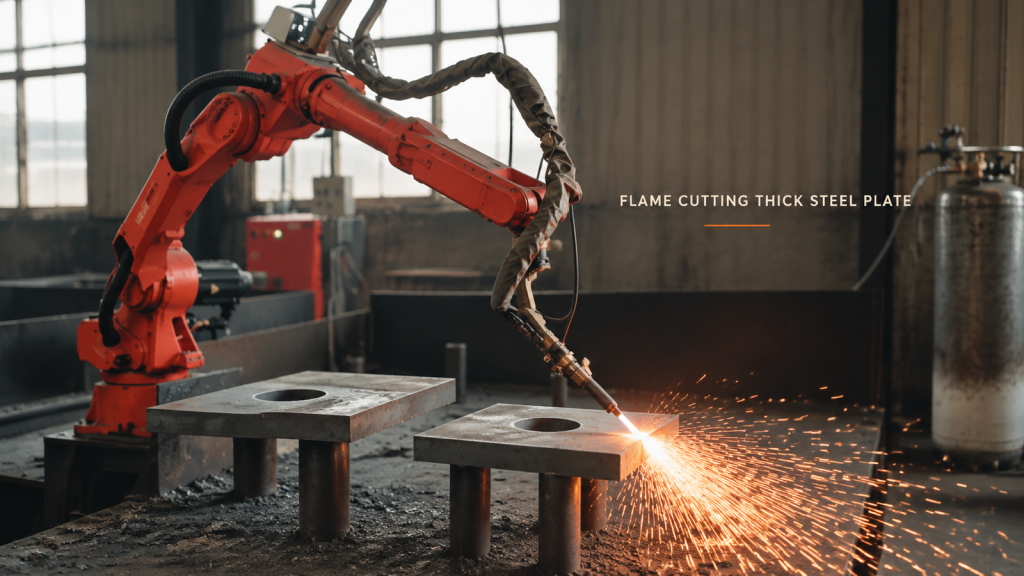
When thick-plate flame cutting can move from a handheld torch to a robot: plate support, torch height along the edge, and keeping people clear of sparks.
Long-Frame Robotic Welding: Which Joint Should Drive the Cell Layout?
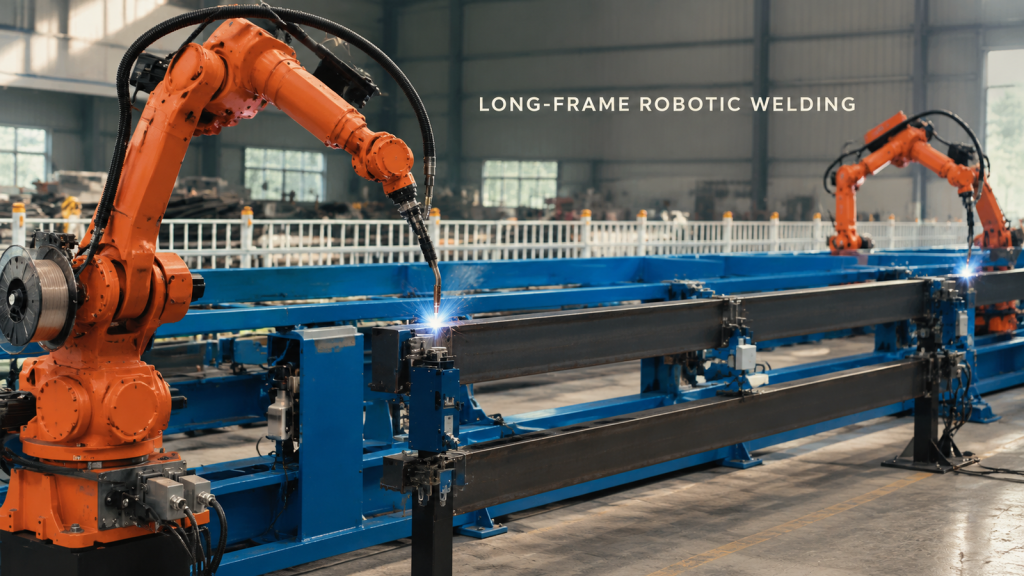
Start a long-frame robotic welding layout with the hardest joint, then validate fixture access, torch posture, cable clearance, and recovery space.
Robotic Bowl-Shaped Part Unloading: How Do You Protect Edges During Withdrawal?
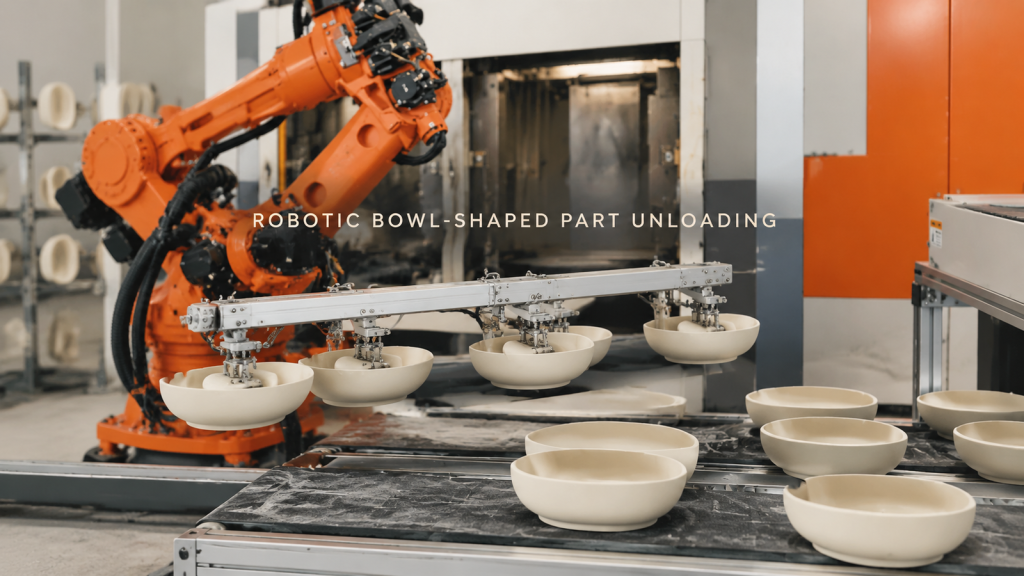
Plan robotic unloading of bowl-shaped parts around supported contact, withdrawal clearance, edge protection, and stable receiving-surface placement.
Robotic Welding of Long-Shaft Assembly Joints: Control Access at the Circular Interface

See a robot weld circular plate joints on a supported long-shaft assembly and plan joint access, fixturing and path segmentation.
Cylindrical-Part Transfer and Equipment Tending: Control the Part at Both Interfaces

See a robot grip short cylindrical parts beside enclosed equipment and plan the pickup, equipment handshake and transfer interfaces.
Robotic Welding of Large Frame Joints: Plan Torch Access Before the First Arc

See an orange robot weld multiple joints on a large fixed frame and learn how torch access, fixturing and path order shape the cell concept.