
Work-Zone Sequencing for Repeated Rail-Component Welds

Explore how work-zone sequencing, fixture consistency and boundary states guide repeated robotic welds on rail components.
Robot Grinding Coverage for Laptop Keyboard Housings
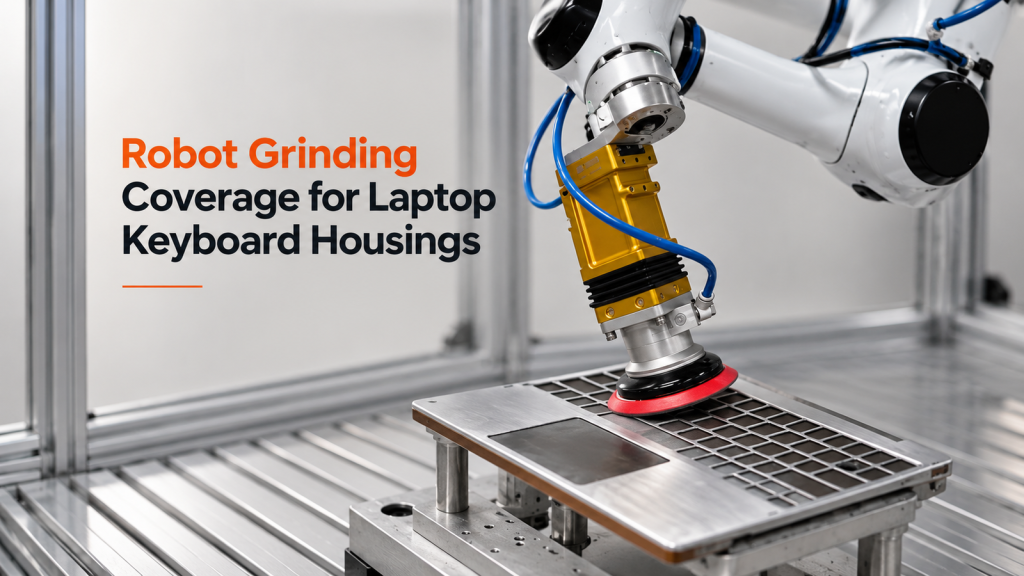
Learn how surface zoning, tool posture and transition checks guide robot grinding paths for laptop keyboard housings.
What Makes a Robotic Tailgate Spray Path Work Around Edges, Masks, and Booth Constraints?
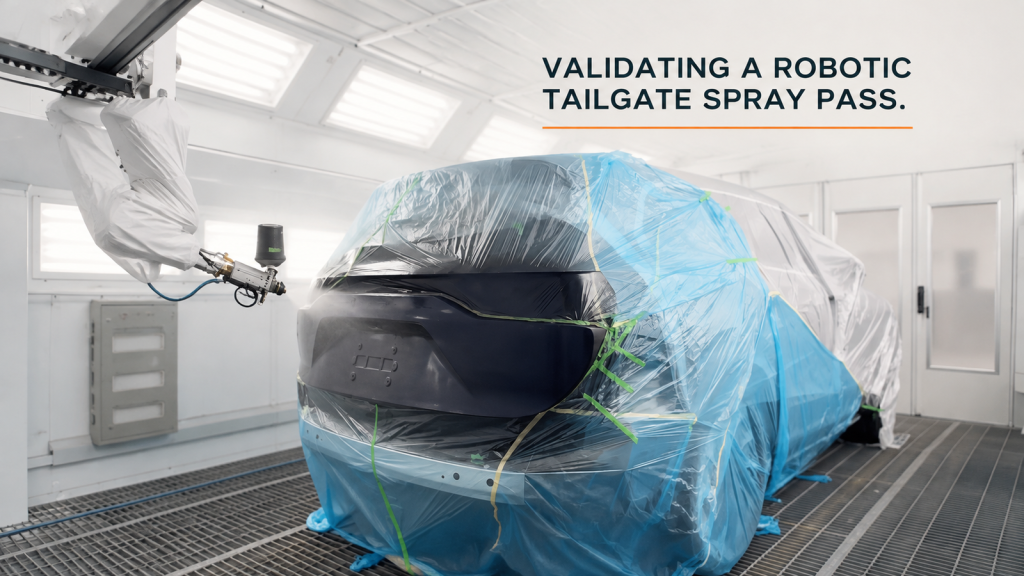
See how surface zones, applicator posture, a top-mounted paint cup, masking boundaries, and booth clearances shape a robotic tailgate spray path.
Robot Press Tending: What Makes the Handoff Between a Tray and Press Repeatable?
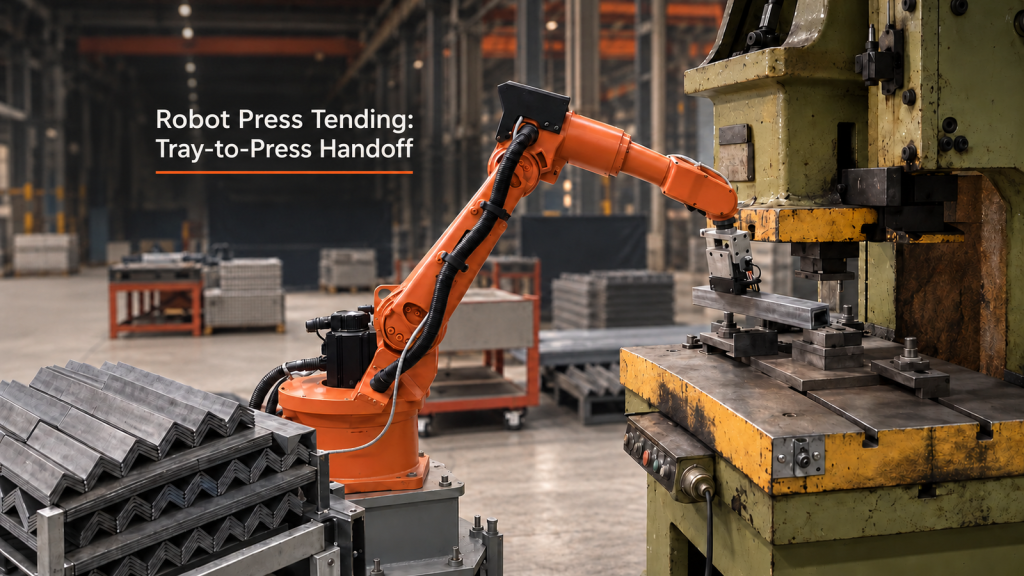
A practical analysis of tray pickup, press permissions, worktable location and recovery for robot press tending.
Planning a Robot Workstation for Conformal Coating: Three Work Areas, One Clear Route
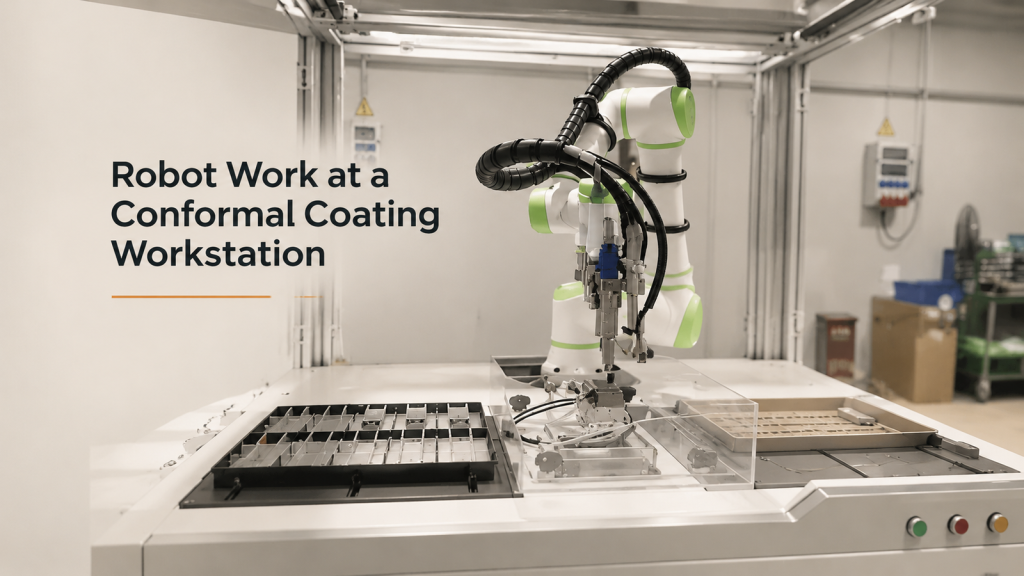
How to plan robot routes, fixture interfaces, occupancy states and recovery across three work areas in a conformal coating workstation.
Mobile Robot CNC Machine Tending
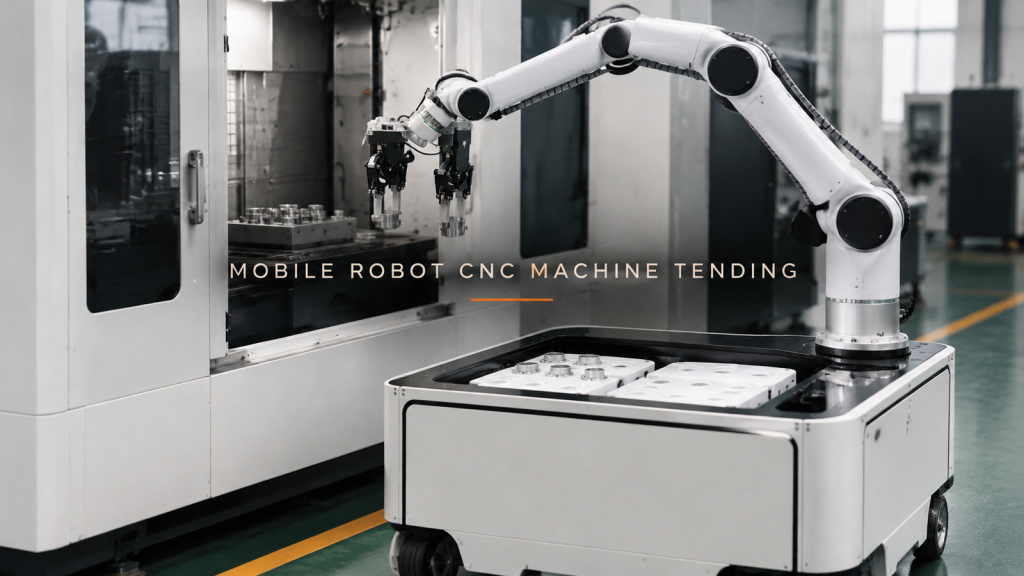
A mobile robot CNC machine-tending concept has to coordinate three interfaces: the tray, the machine opening, and the docking position that makes both reac
Robotic Adhesive Spraying for Instrument Panels
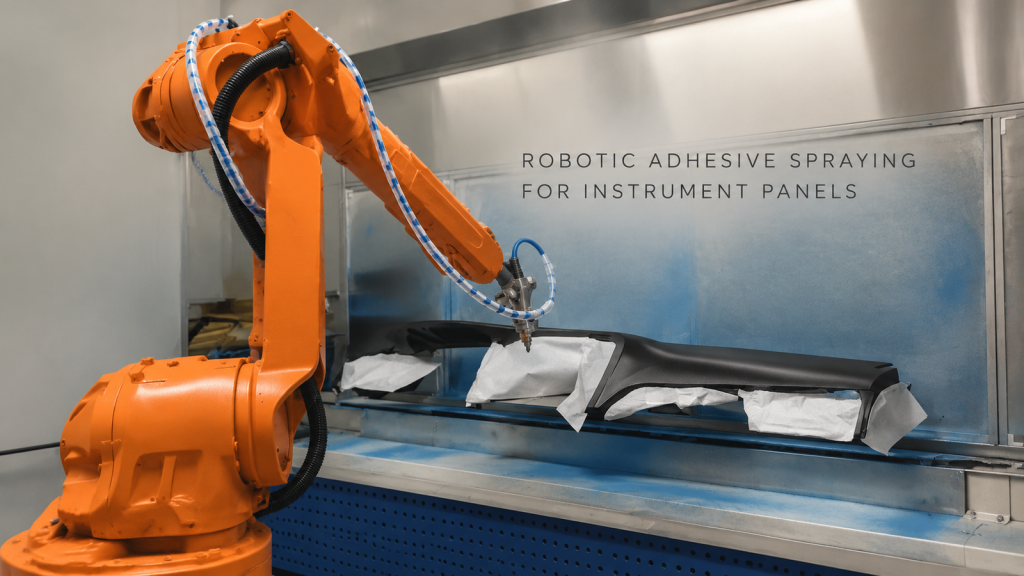
See a robot approach, follow and reposition across an instrument panel, then review path, clearance and validation inputs for a practical project.
Robot Seam Welding on a Ribbed Box-Shaped Workpiece: What the Joint Path Demands
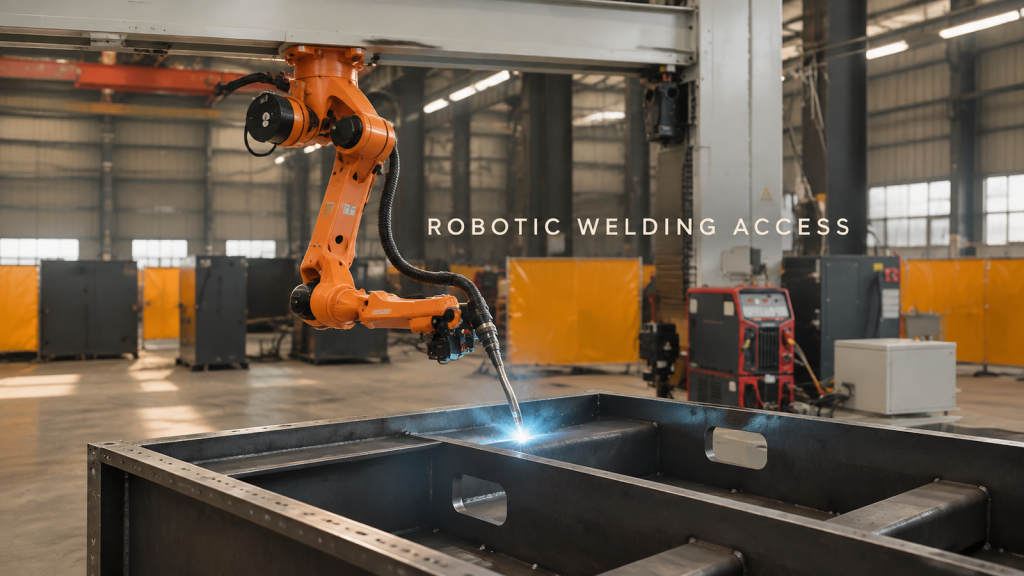
A field video shows a robot welding along a seam on a ribbed box-shaped workpiece. See the geometry, access and validation inputs that matter.
Robot Seedling Tray Palletizing: Building Alternating Layers and Discharging the Pallet
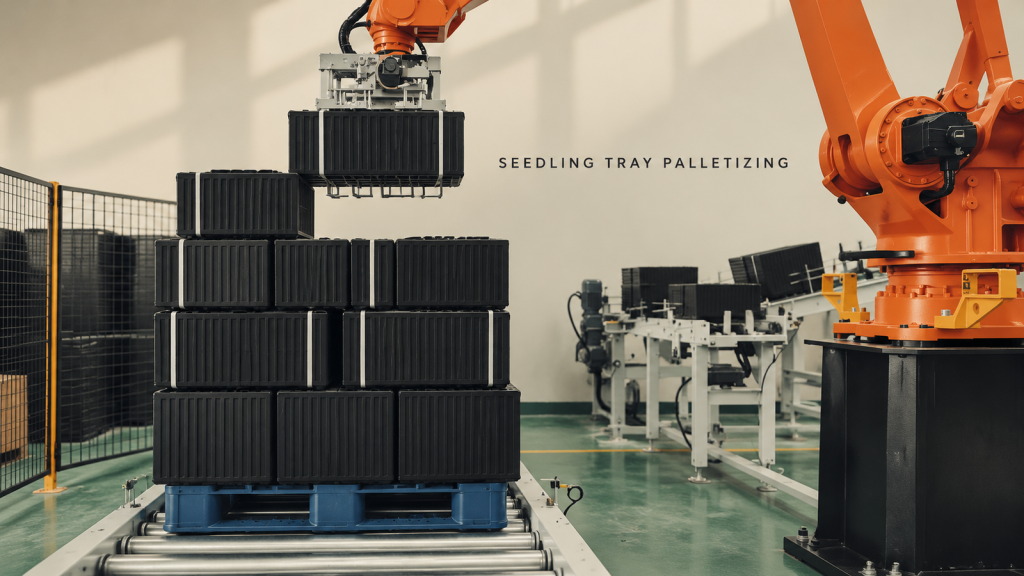
See stacked seedling tray groups picked, placed in alternating layer orientations and discharged as a complete pallet load.
Robot Grinding for Jack Components: Coordinating a Rotary Fixture and Tool Access
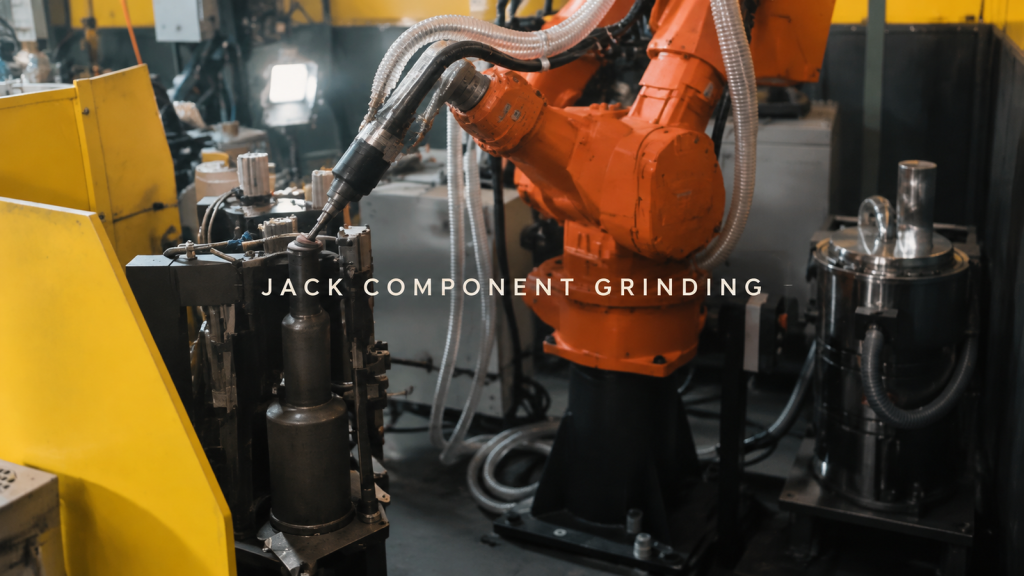
See how a rotary fixture presents jack components for robot grinding, with rear and front-lower contact routes, indexing interlocks and clearance checks.
What Keeps a Long Sheet-Metal Argon-Arc Seam Stable from Start to End?
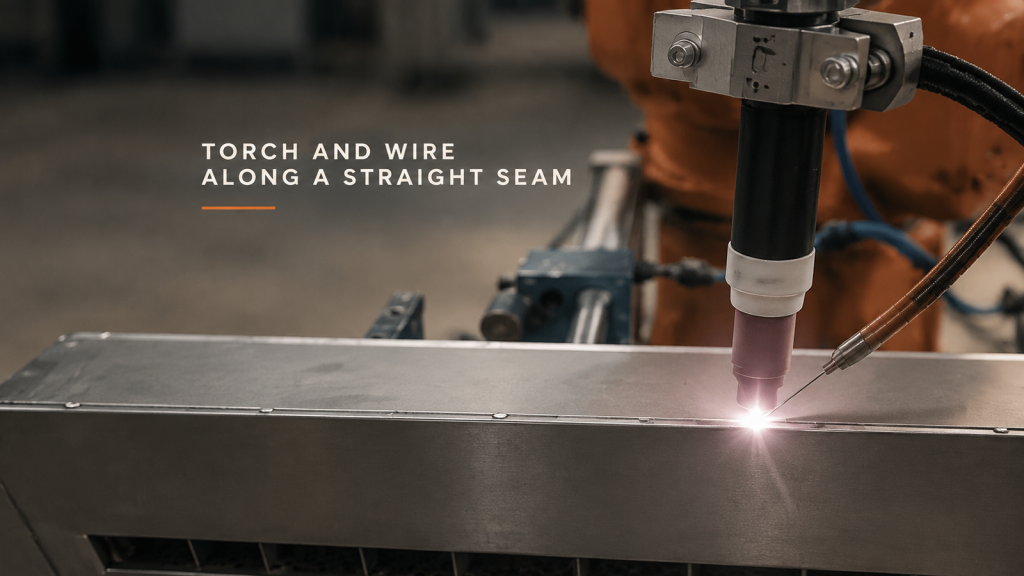
Plan a long sheet-metal argon-arc seam around joint stability, ceramic-nozzle and side-wire geometry, and a defined arc-ending zone.
Robot-Held Part Deburring: How Should Gripping Faces and Working Edges Be Divided?
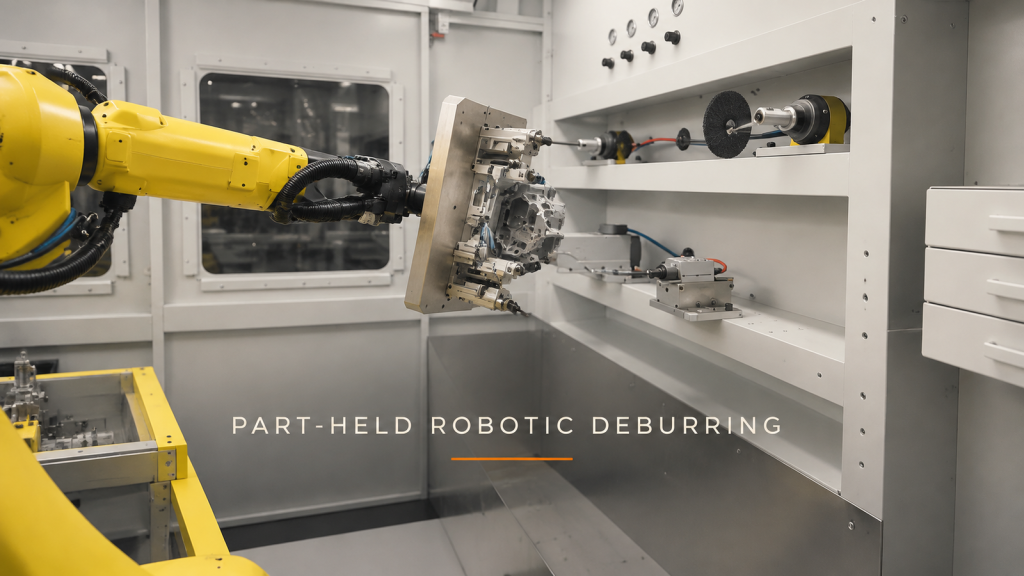
Plan robot-held part deburring by separating gripping faces from working edges, checking fixture clearance and defining each fixed-tool approach.