
Robot Press Tending on a Wheel Rim Line: What Decides Whether It Can Be Handed Over?
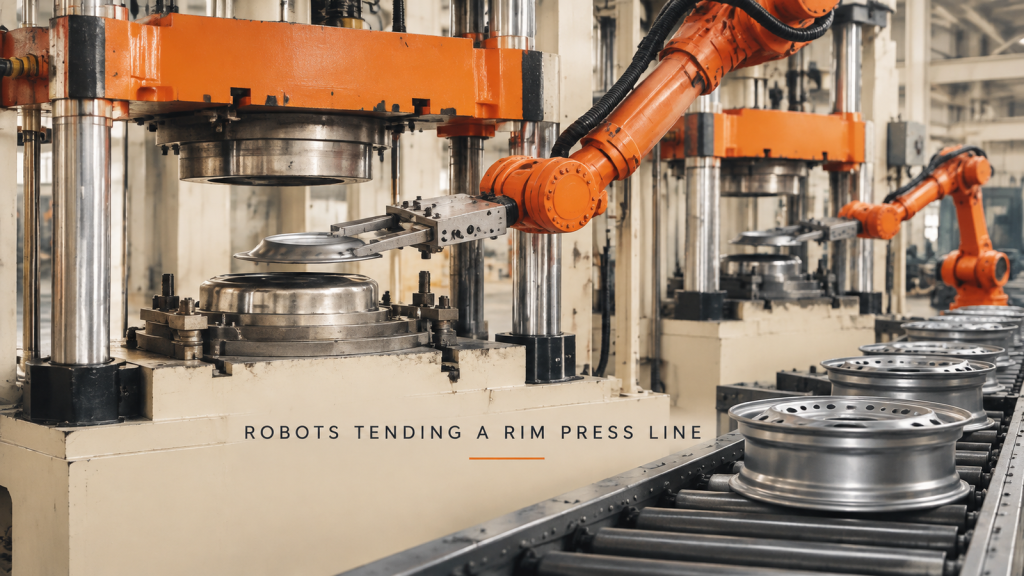
Robot press tending on a wheel rim line: carrying the part into the die, the robot-press interlock, part location, and scaling from one press to a row.
Loading Yarn Bobbins onto a Creel with a Cobot: What Does the Cell Have to Get Right?
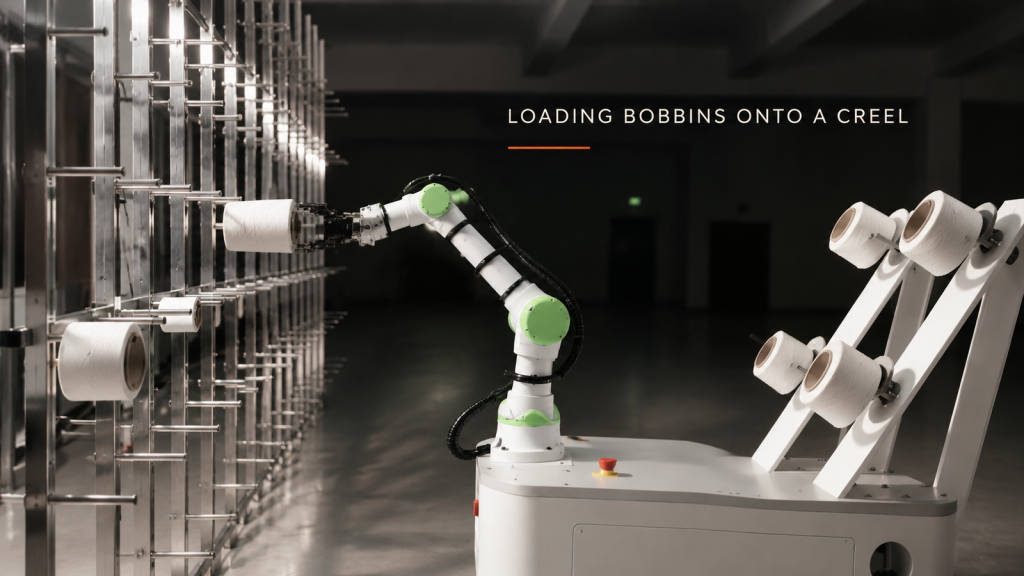
Loading yarn bobbins onto a creel with a cobot: grip clear of the yarn, bore-to-peg alignment, reach to top and bottom pegs, and where a mobile base fits.
Robot Flame Cutting of Thick Steel Plate: When Can the Handheld Torch Move to a Robot?
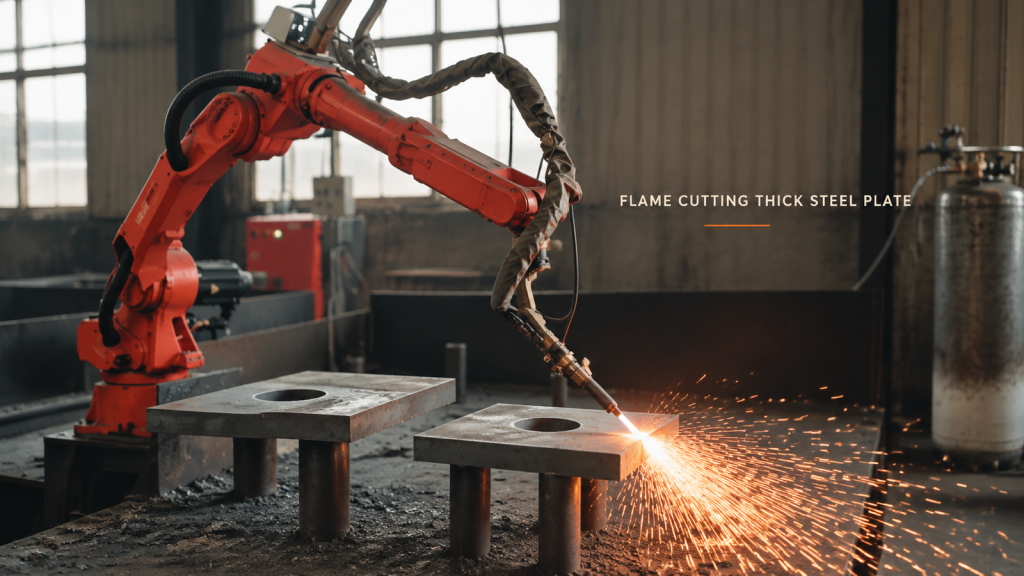
When thick-plate flame cutting can move from a handheld torch to a robot: plate support, torch height along the edge, and keeping people clear of sparks.
Long-Frame Robotic Welding: Which Joint Should Drive the Cell Layout?
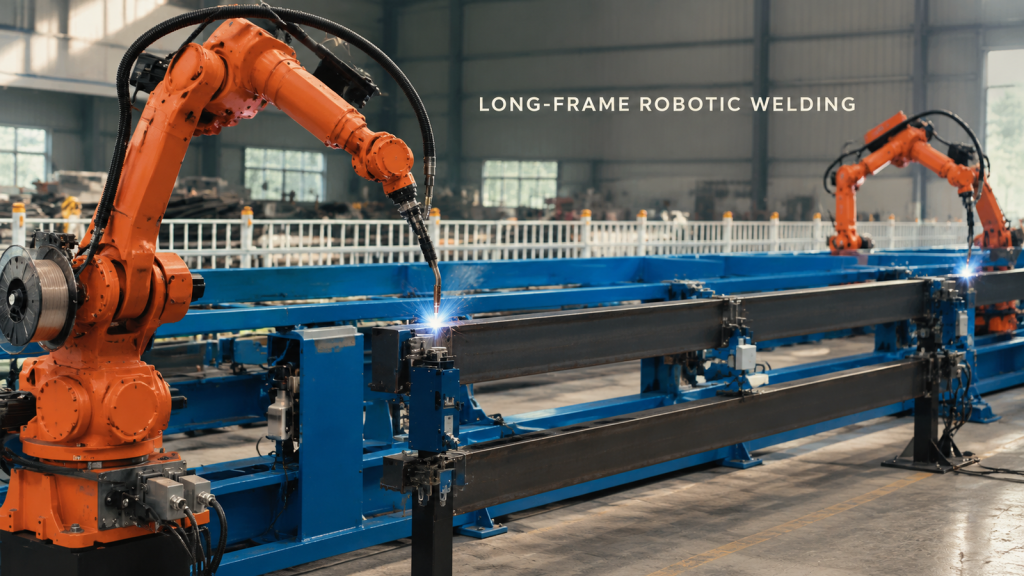
Start a long-frame robotic welding layout with the hardest joint, then validate fixture access, torch posture, cable clearance, and recovery space.
Robotic Bowl-Shaped Part Unloading: How Do You Protect Edges During Withdrawal?
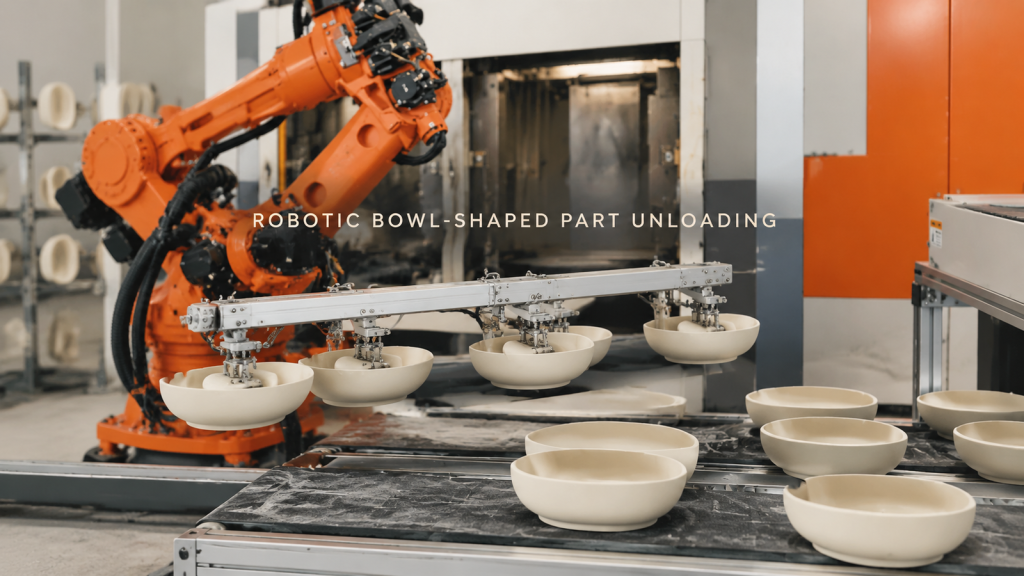
Plan robotic unloading of bowl-shaped parts around supported contact, withdrawal clearance, edge protection, and stable receiving-surface placement.
Robotic Welding of Long-Shaft Assembly Joints: Control Access at the Circular Interface
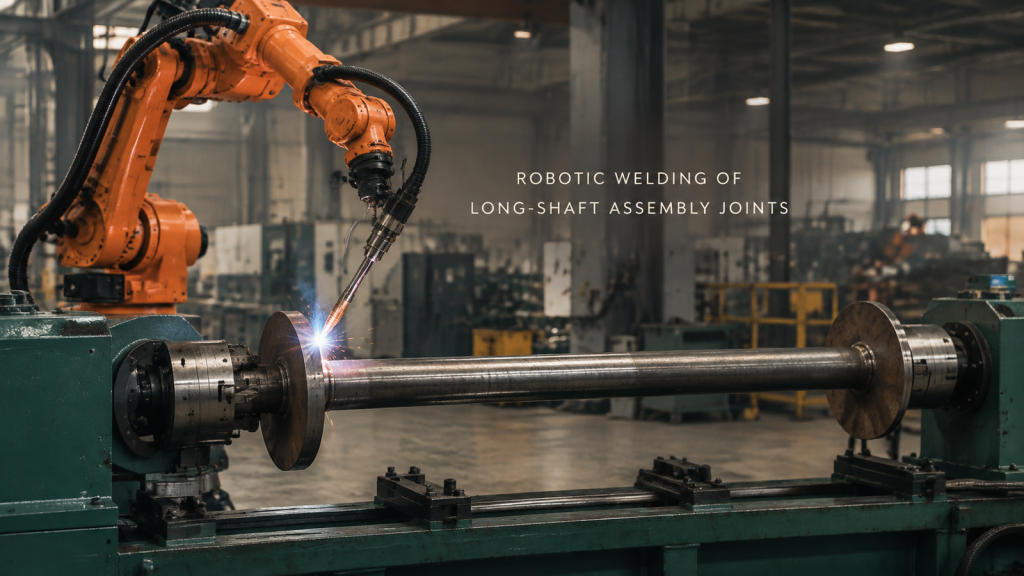
See a robot weld circular plate joints on a supported long-shaft assembly and plan joint access, fixturing and path segmentation.
Cylindrical-Part Transfer and Equipment Tending: Control the Part at Both Interfaces
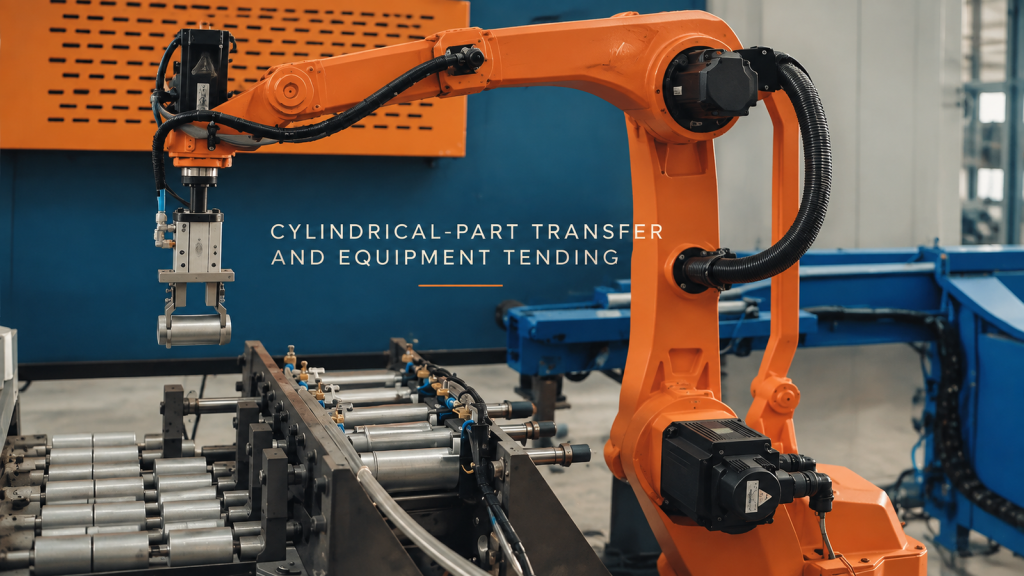
See a robot grip short cylindrical parts beside enclosed equipment and plan the pickup, equipment handshake and transfer interfaces.
Robotic Welding of Large Frame Joints: Plan Torch Access Before the First Arc
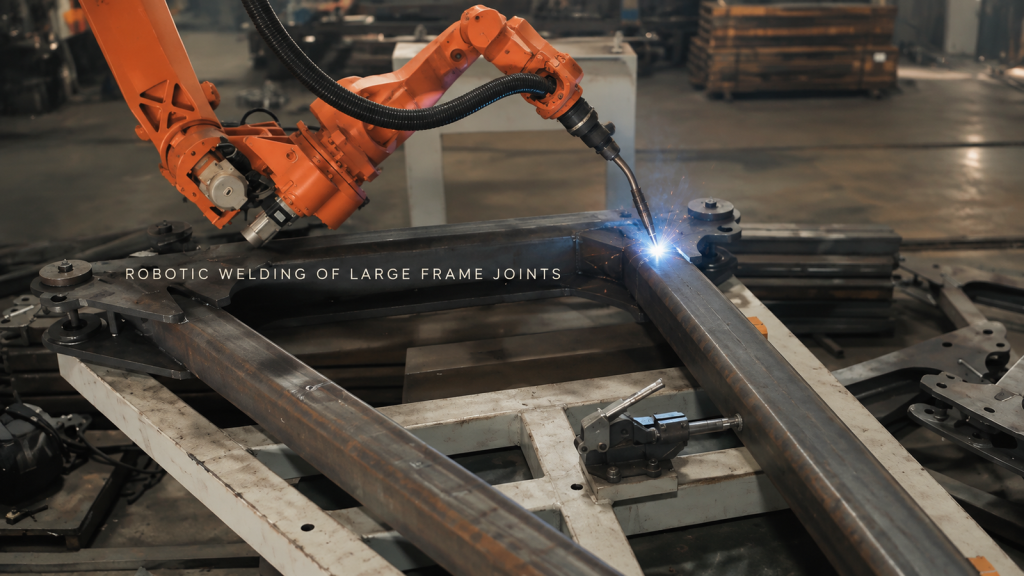
See an orange robot weld multiple joints on a large fixed frame and learn how torch access, fixturing and path order shape the cell concept.
Laser Trimming a Stamped Car Door Panel: One Robot, a Cutting Head and a Stand
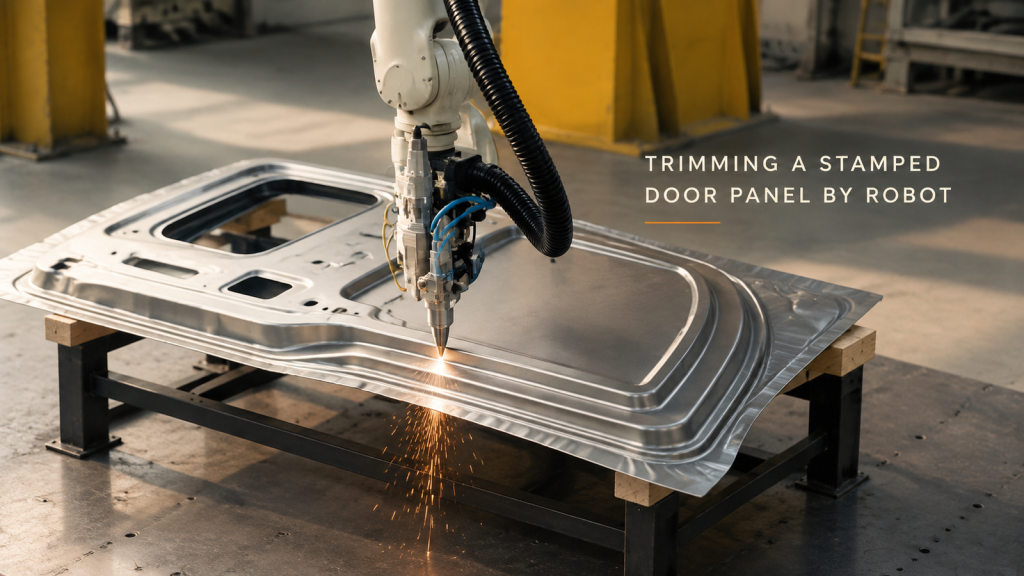
How one robot traces the contour of a stamped car door panel with a laser cutting head — the pass, the sparks at the edge, and three decisions that keep the cell repeatable.
Battery Module Handling: One Robot Between a Conveyor and a Station
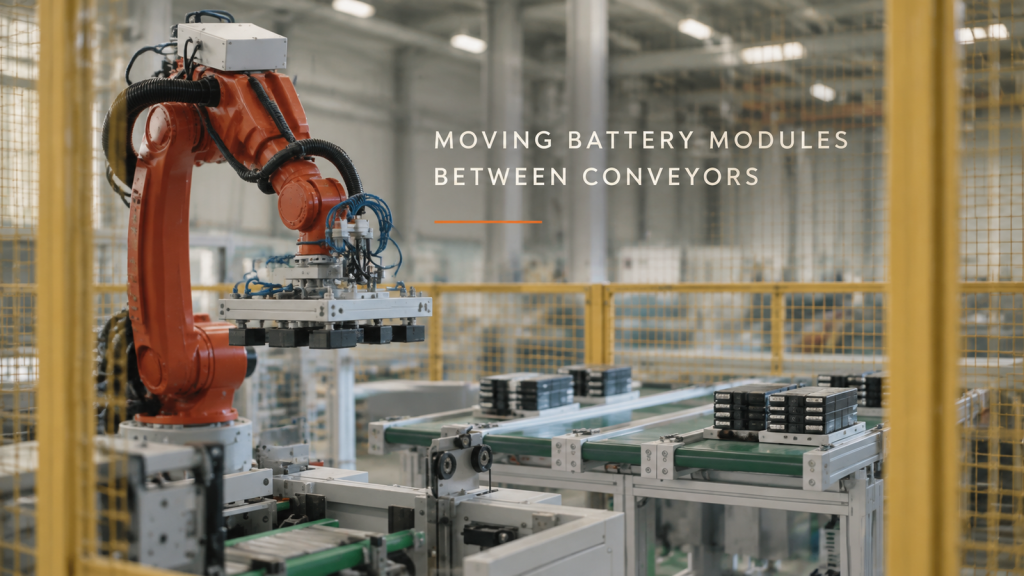
How one six-axis robot inside a safety fence moves grouped battery modules between a conveyor line and a station — the loop, the end-of-arm tool and how the line shares the cycle.
Painting Motorcycle Brake Parts: One Robot on the Hanger Line
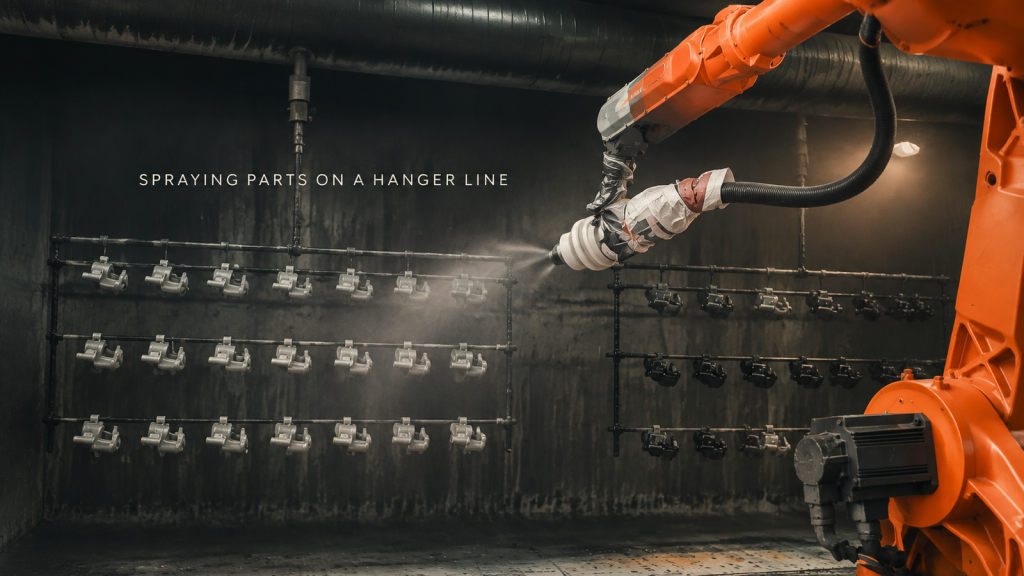
How a paint booth paints rows of motorcycle brake parts on a hanger line with one six-axis robot — the loop, how the parts hang, how the gun sweeps and where the overspray ends up.
Welding Large Steel Structures: Multiple Robots, Multiple Stations
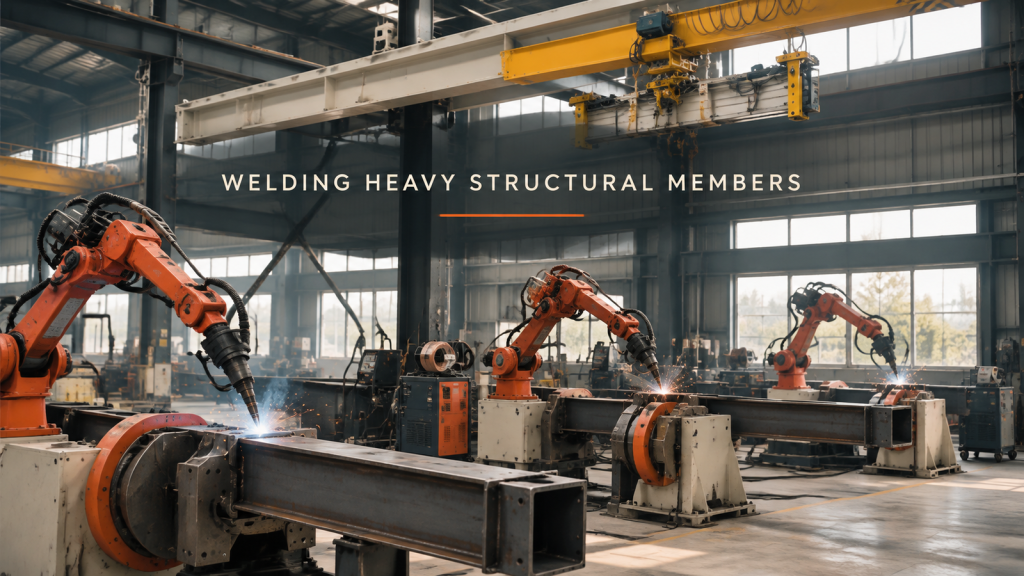
How a shop welds large box- and angle-section steel members with several six-axis robots on positioners — the loop, clamping and turning the part, torch reach and how the stations divide the work.