
Moving one carton from a stacked load to an outbound conveyor looks repetitive, yet the handoff changes as the layer is depleted. In this case, a robot lifts individual cartons from a stack on the right, carries them across the cell and releases them onto a green conveyor on the left. The engineering task is to keep pickup geometry, carton retention and conveyor release predictable from the first carton to the last.
Send EVST the carton specification, pallet pattern, conveyor layout and daily output target for an initial solution and cycle assessment: https://www.evsint.com/contact/#quote
Convert the stack pattern into reachable pick states
Describe every layer with carton count, orientation, nominal center points, separators and expected stack tolerance. The controller needs an explicit rule for advancing through those positions and for confirming when a layer is complete. Pallet placement and accumulated lean should be included in the tolerance study. Record the coordinate source for every pick position so that a pattern revision can be checked without rewriting unrelated states.
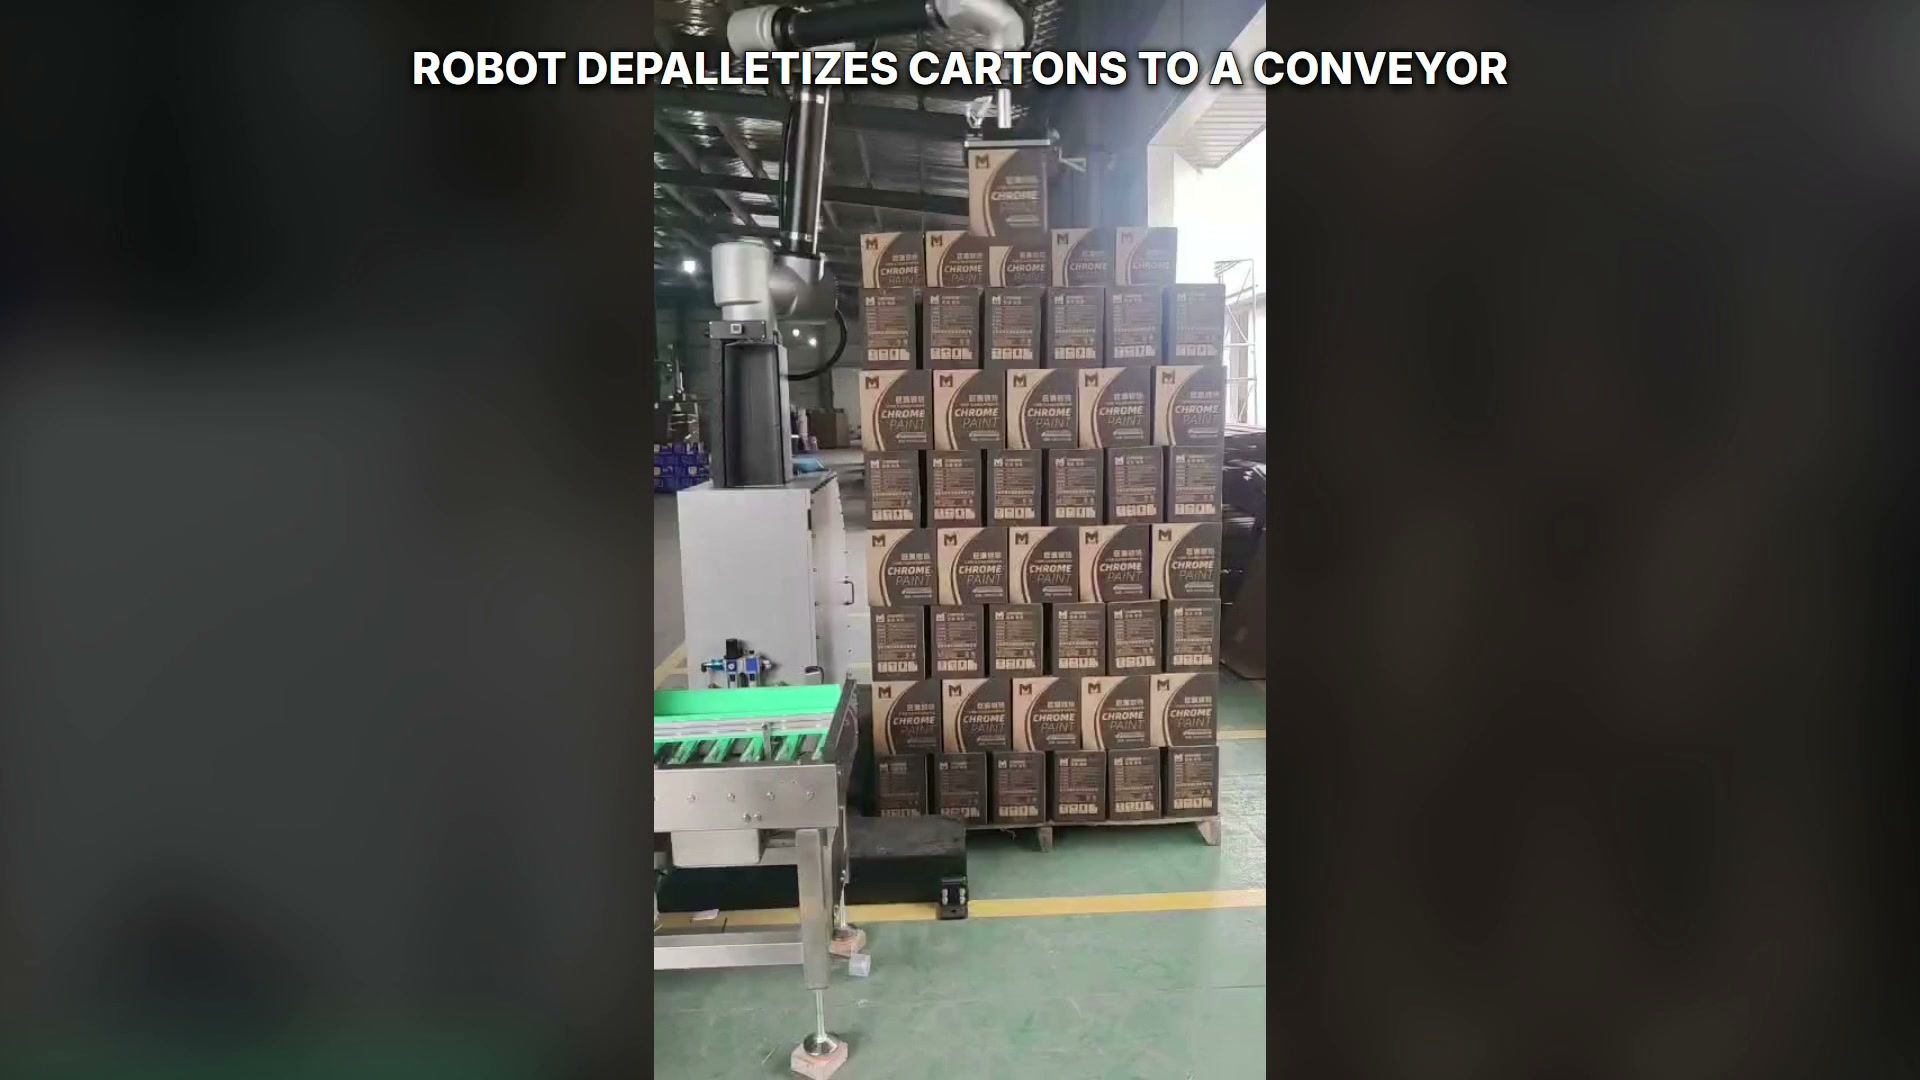
The robot holds one carton above the right-hand stack.
The first layout review should test the highest, lowest, nearest and farthest pick states. Check robot posture, tool clearance, pallet edges and surrounding equipment at each corner of the pattern instead of validating only a central carton.
Match the end effector to carton variation
Carton stiffness, surface condition, seams, tape, lids and local deformation affect the available gripping area. Define permitted contact zones and the confirmation method before selecting the final tool. Vacuum-zone monitoring, pressure behavior or another project-specific signal can be evaluated with representative cartons.
The tool should retain the carton through acceleration and deceleration while avoiding contact with neighboring cartons. Trials should include the allowed carton range and realistic packaging condition, then establish alarm limits from recorded results.
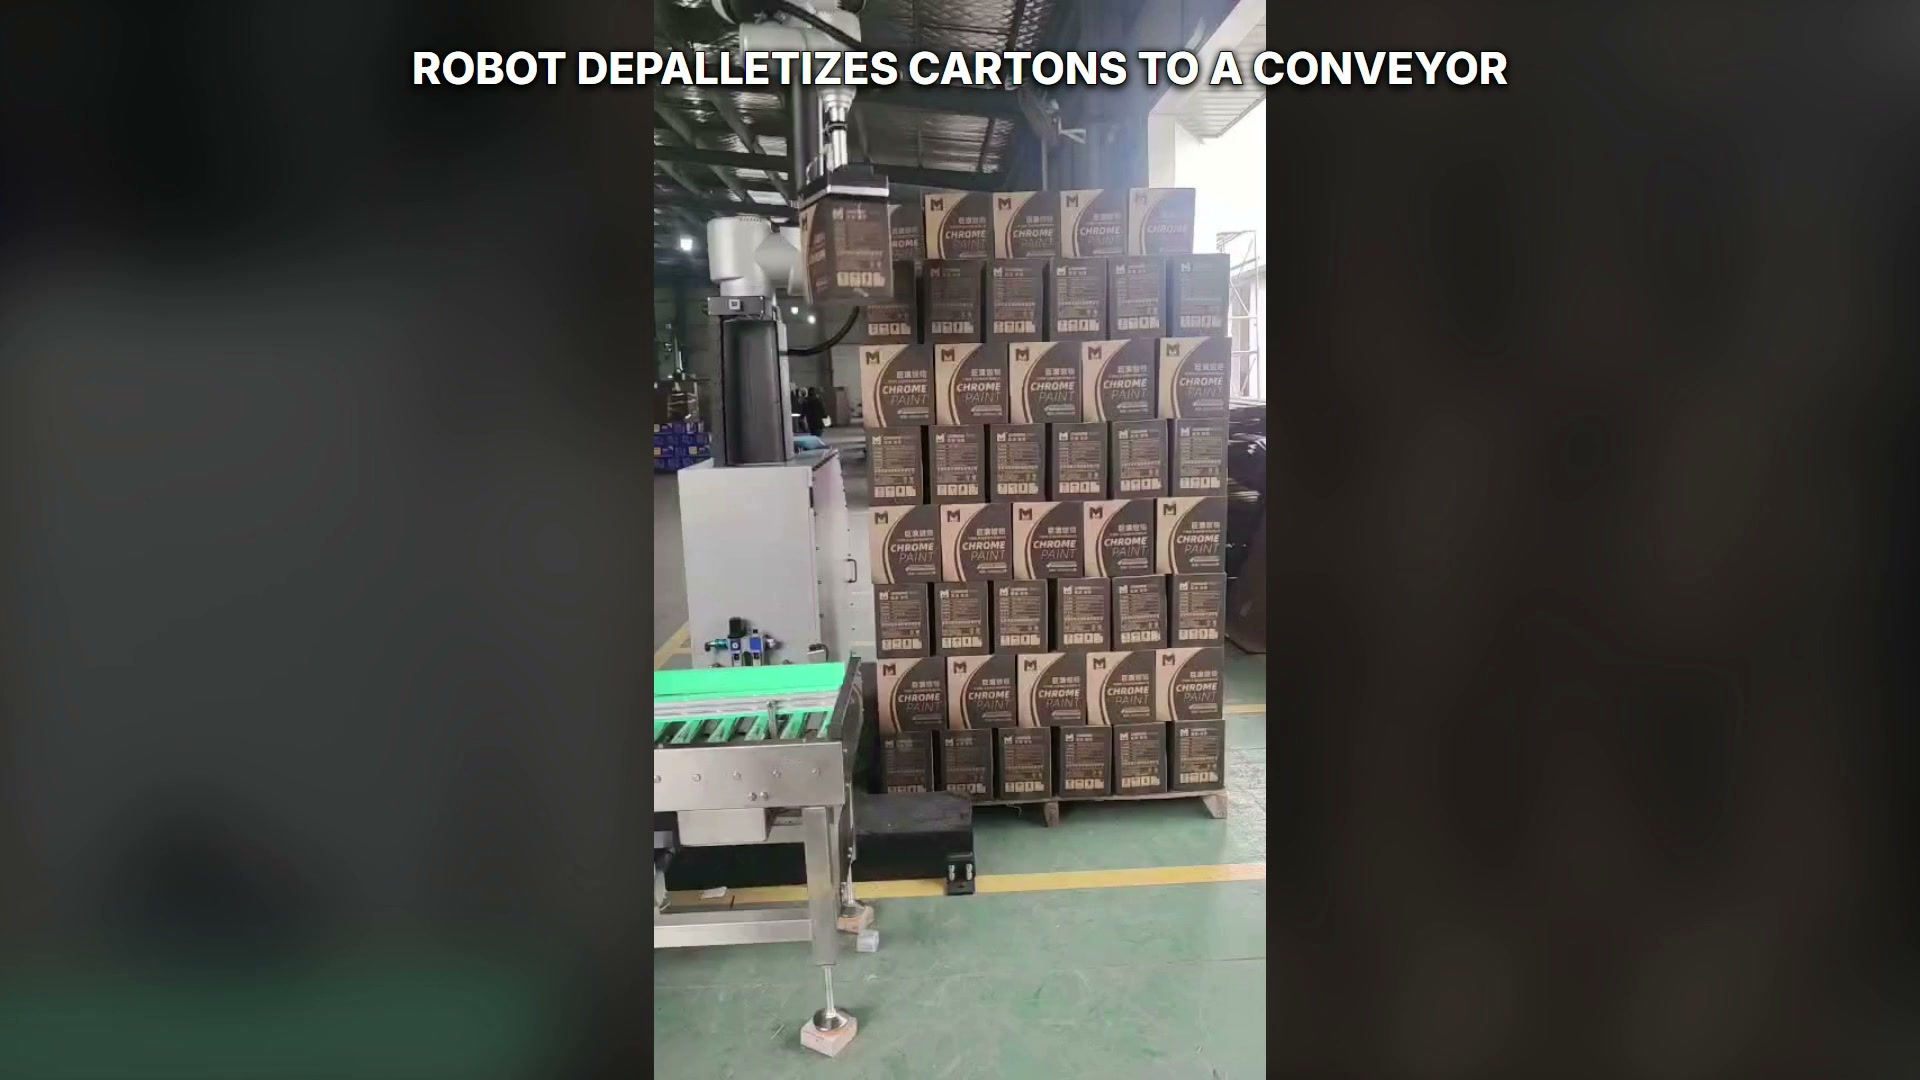
The robot holds one carton between the stack and the conveyor; the conveyor is empty in this view.
Treat conveyor release as a controlled handoff
The conveyor must provide a known release zone and enough downstream capacity. Define the conveyor-ready signal, target position, robot release condition and proof that the carton has cleared. The conveyor should not advance into a conflicting state while the robot tool remains inside its envelope.
| Handoff | ورودی پروژه | بررسی پذیرش |
|---|---|---|
| Stack to tool | Pallet pattern, stack tolerance, carton contact zones | Selected carton is retained without disturbing neighbors |
| انتقال ابزار | Load range, acceleration trial, collision envelope | Carton remains controlled through the full route |
| Tool to conveyor | Release zone, conveyor state, clearance signal | Carton is supported before release and clears the robot |
| Interrupted cycle | Known carton and tool state, safe retreat | Restart does not skip or repeat a stack position |
OSHA industrial robot systems chapter provides general risk-assessment context. EVST’s palletizing robot overview provides related product and layout context; the transfer direction in this case remains stack to conveyor.
Keep stack state traceable during recovery
A stop can occur before pickup, after retention, during transfer or after conveyor release. The recovery screen should identify the commanded stack position, whether the tool is believed to hold a carton, conveyor occupancy and the next permitted action. Operator confirmation should update the same state model used by automatic operation.
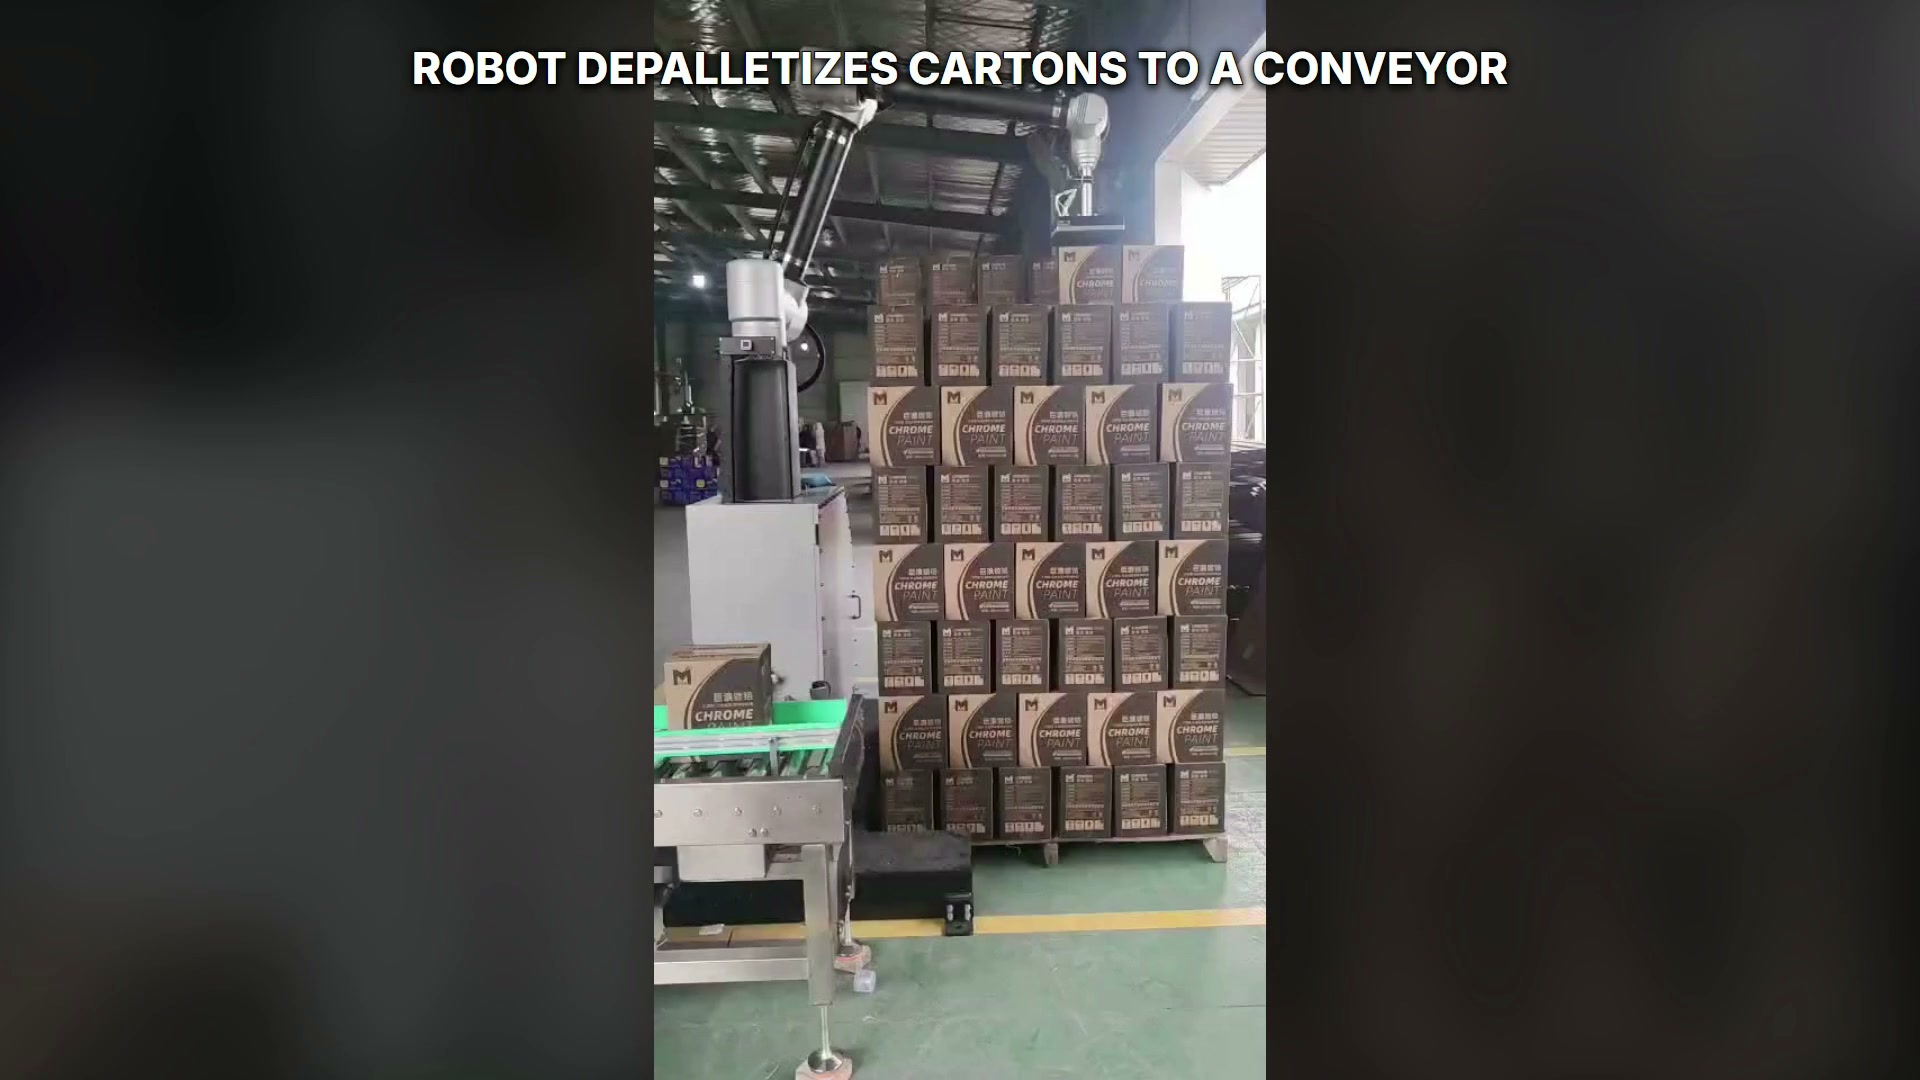
One carton rests on the green conveyor while the robot tool is empty above the stack.
Measure the complete material flow
Cycle assessment should include pallet presentation, pick confirmation, robot motion, conveyor release, downstream clearance, pallet exchange and planned operator tasks. Record these elements separately under agreed carton and pallet conditions so that the limiting interface can be identified.
سوالاتی که خریداران باید به آنها پاسخ دهند
چه اطلاعاتی باید ابتدا ارائه شود؟
Provide carton dimensions and allowed variation, representative samples, pallet and layer patterns, separator details, conveyor layout, available signals and daily output target.
How should a tool concept be tested?
Use cartons spanning the approved condition range, test permitted pickup zones and record the retention signal through representative motion.
What prevents a release conflict?
Use a defined conveyor-ready state, a fixed or referenced release zone, confirmation that the carton is supported, and a robot-clear signal before conveyor movement.
What should happen after an interruption?
Reconcile the physical stack, tool and conveyor state with the controller, then select a documented retreat, completion or manual-handling step.
For a project review, send carton data, pallet patterns, conveyor interfaces and daily output target to EVST: https://www.evsint.com/contact/#quote or sales@evsrobot.com.
Case context: individual cartons move from a right-hand stacked load to a left green conveyor.