
Tank Structures: Turn the Fillet or Move the Torch
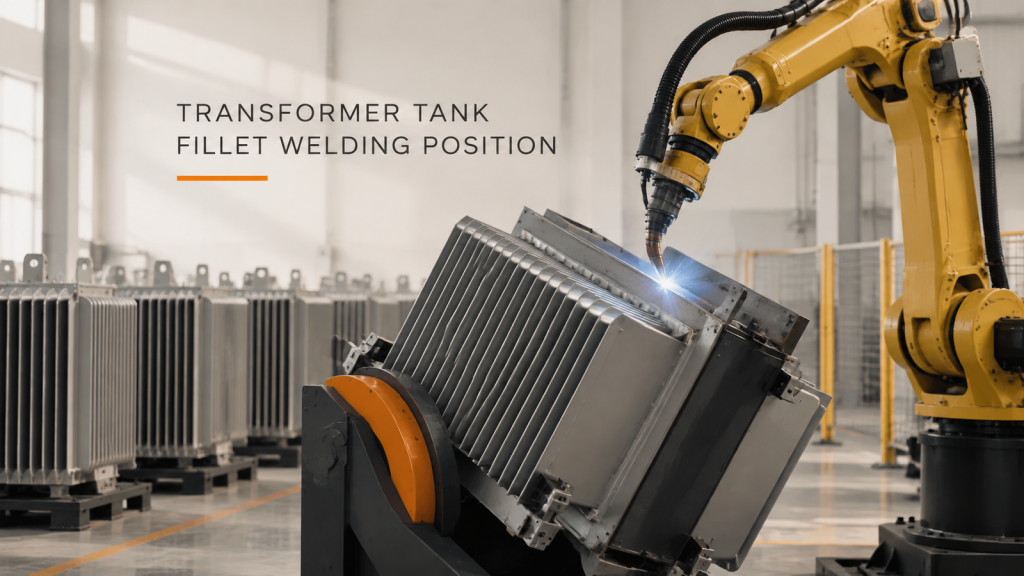
Tank assemblies carry two seam families: long seams are a heat-input problem, stiffener fillets an access problem. They are not solved alike.
Rail, Positioner, or Both: Large Structure Welding
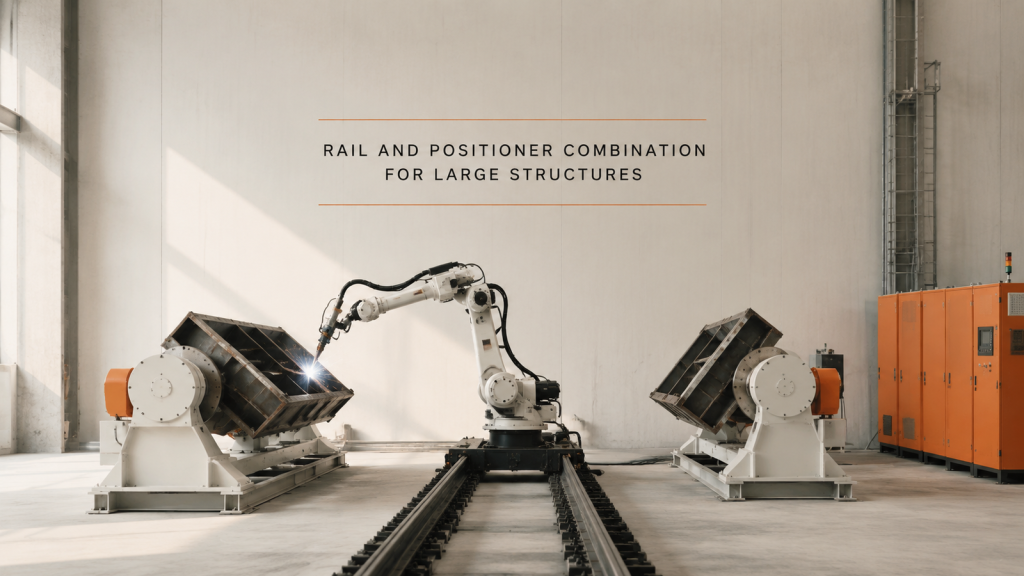
A rail answers reach and a positioner answers attitude. Deciding which a large structure needs starts with the seam list, not with the equipment catalogue.
Intersecting Pipe Joints: Fit-Up Decides the Weld
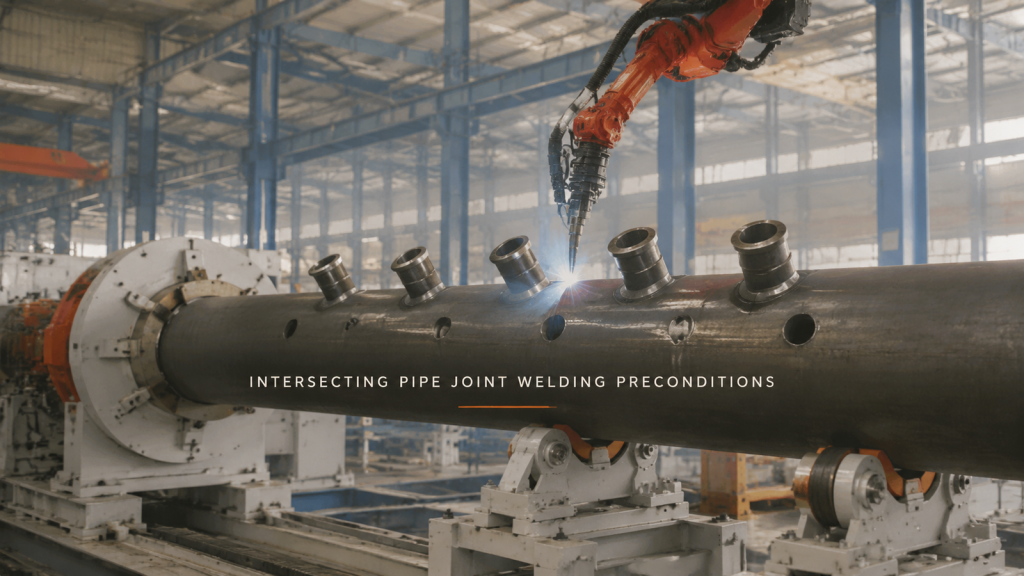
On branch-to-header joints the limiting factor is rarely reach. Hole position, bevel and assembly gap decide whether the seam can be welded in one pass.
Teach-Free Welding: Where It Actually Holds Up
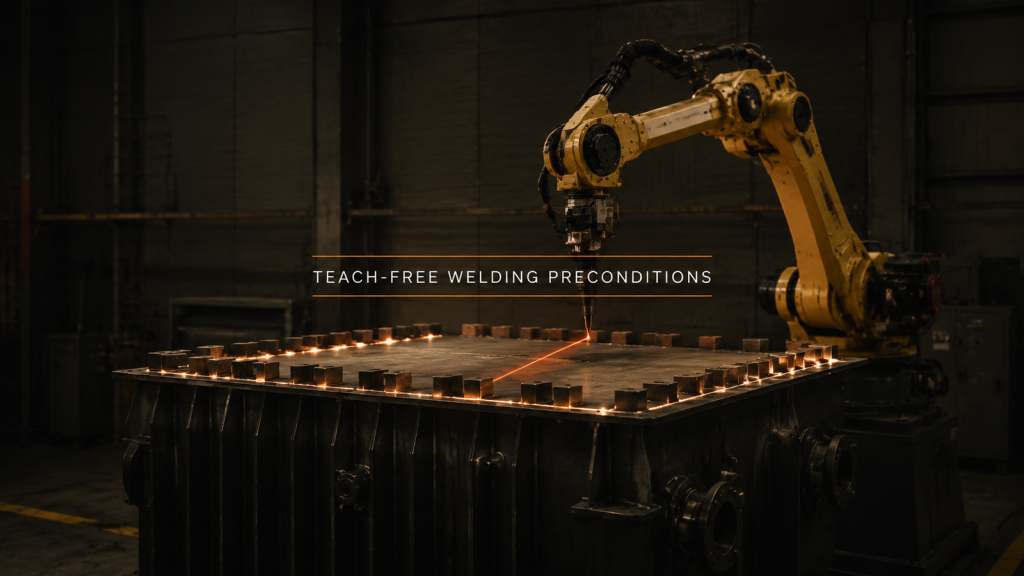
Teach-free welding removes the teaching, not the locating. It holds up where the seam is regular and the variation is something the scan can see.
Welding Fume and Arc Light: The Part Decides
Whether fume can leave a weld is set by how enclosed the part is, and shielding follows where people walk, not the machine footprint.
On-Site Robotic Welding: Floor, Blocking, Cable
When the part cannot be lifted, the welding unit drives to it, and the floor, the blocking and the trailing cable become the setup.
Dedicated Welding Machine or Robot: Is the Product Settled?
Dedicated welding machine versus robot selection turns on how settled the product is: what each arrangement buys, and what change costs.
Fan Manufacturing Automation Retrofit: Constraints First
A fan manufacturing automation retrofit faces a chain, not a station. List the constraints before choosing any robot.
Prefabrication Automation: Cost the Handover
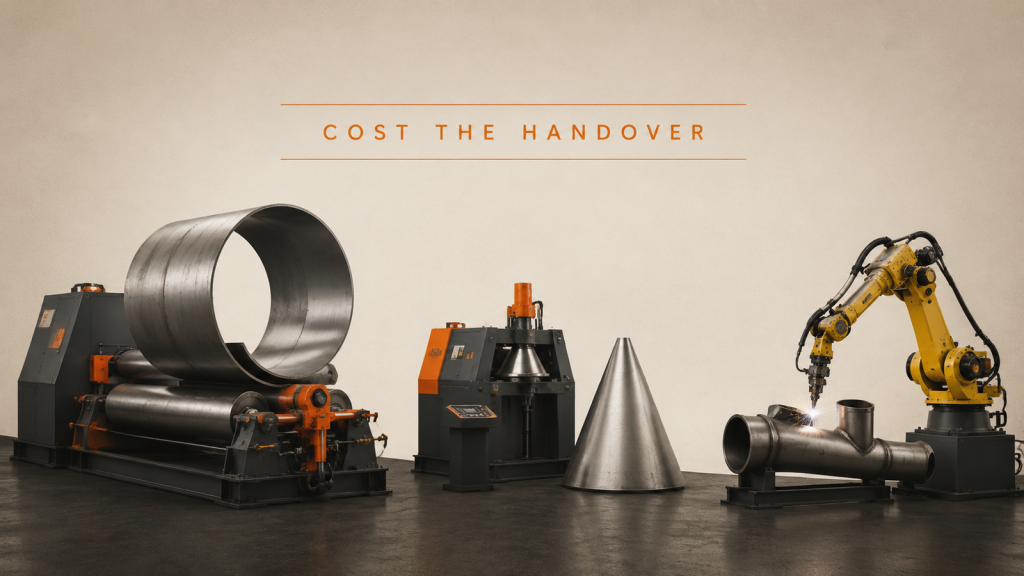
In prefabrication automation, rolling, forming and welding each automate well on their own. What governs output is the handover between them.
Robotic Head Cutting: Path, Attitude and Edge
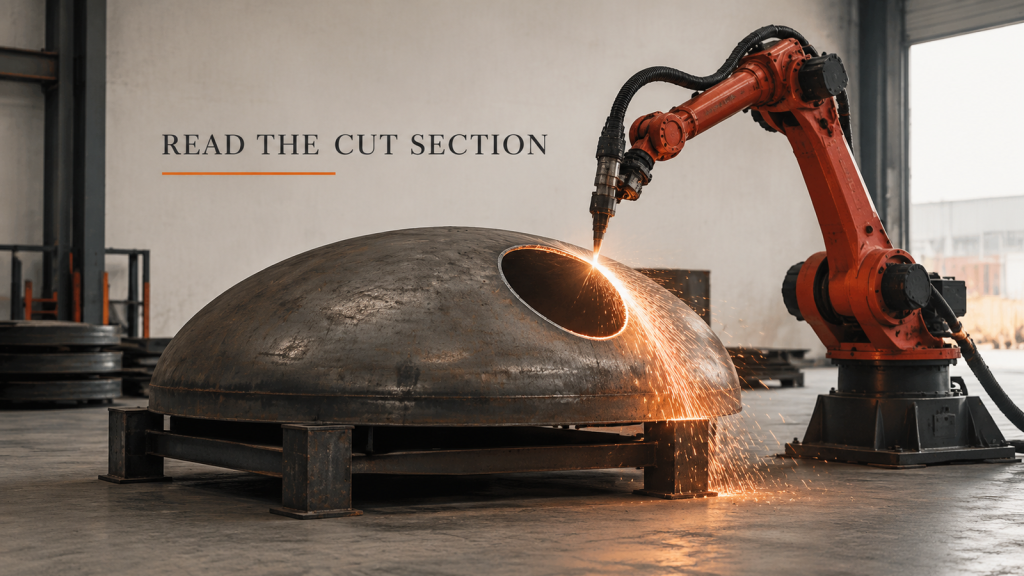
Robotic head cutting puts a closed path on a curved surface. Plan the path and the torch attitude together, then judge the cut edge.
SCARA Robot or Six-Axis: Let the Motion Choose
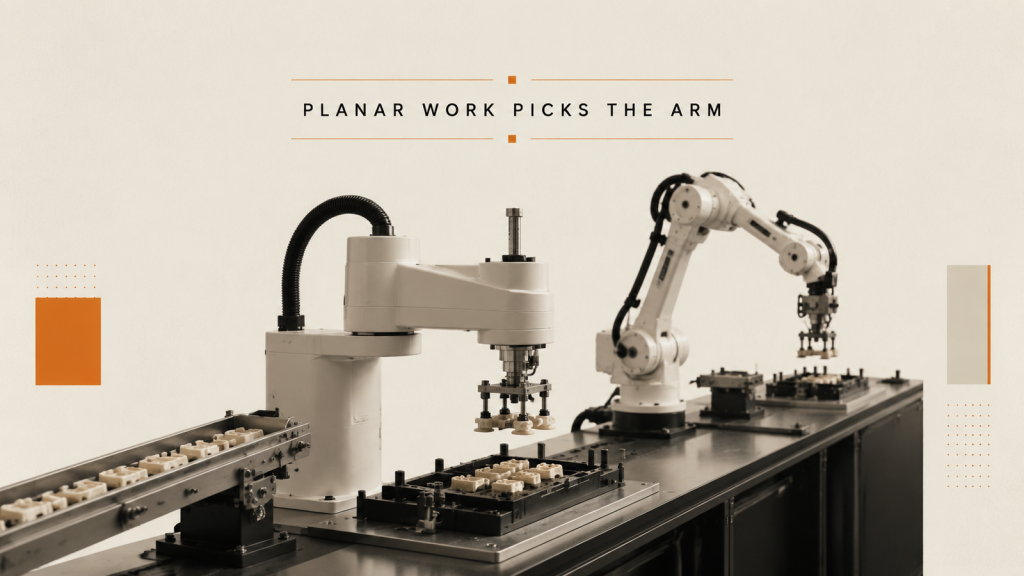
Choosing a SCARA robot or a six-axis arm for small part assembly starts with the motion of each step, not with the axis count in a catalogue.
Robot Payload: Why the Gripper Belongs in It
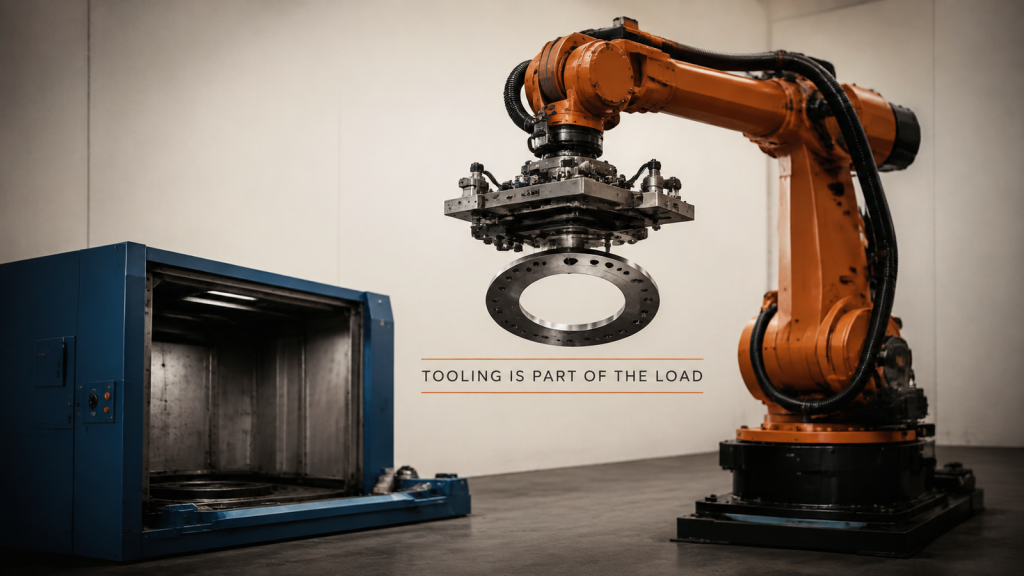
Robot payload has to cover the tooling and the part together, at the real distance between the wrist flange and the centre of mass.