
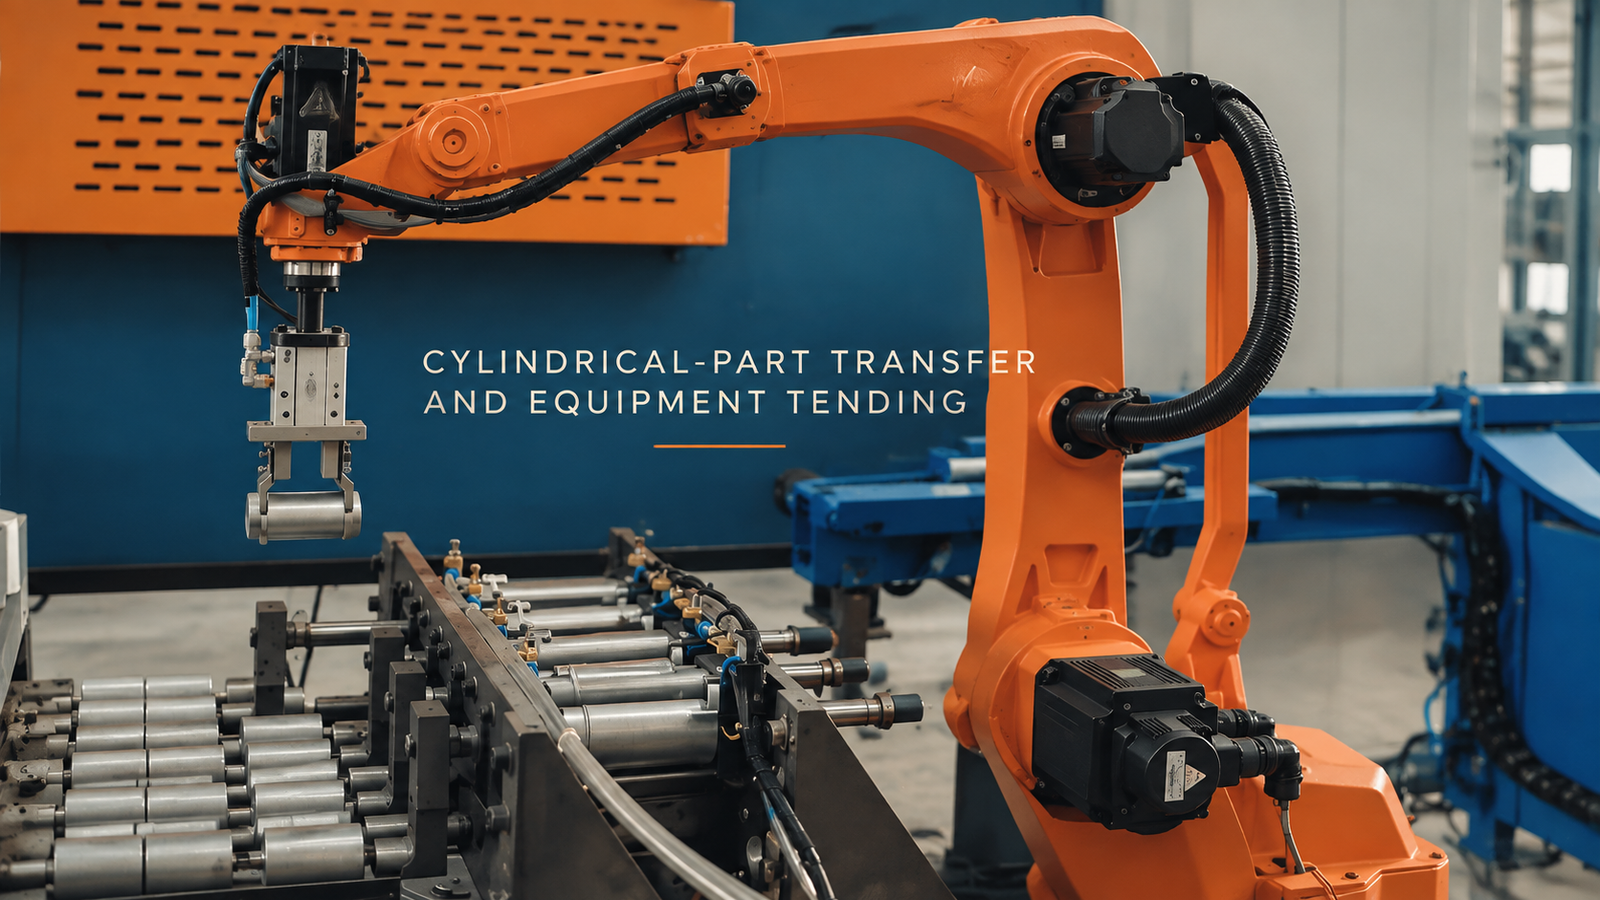
Holding a cylindrical part does not mean the equipment handoff is complete. The pickup must establish radial and axial pose; the equipment interface must then accept that known pose through a clear opening and defined control state. The footage shows an orange robot, a downward parallel gripper, short cylindrical parts and blue enclosed equipment, without identifying the equipment process. Ask EVST to review your application →
Grip is useful only when it establishes pose
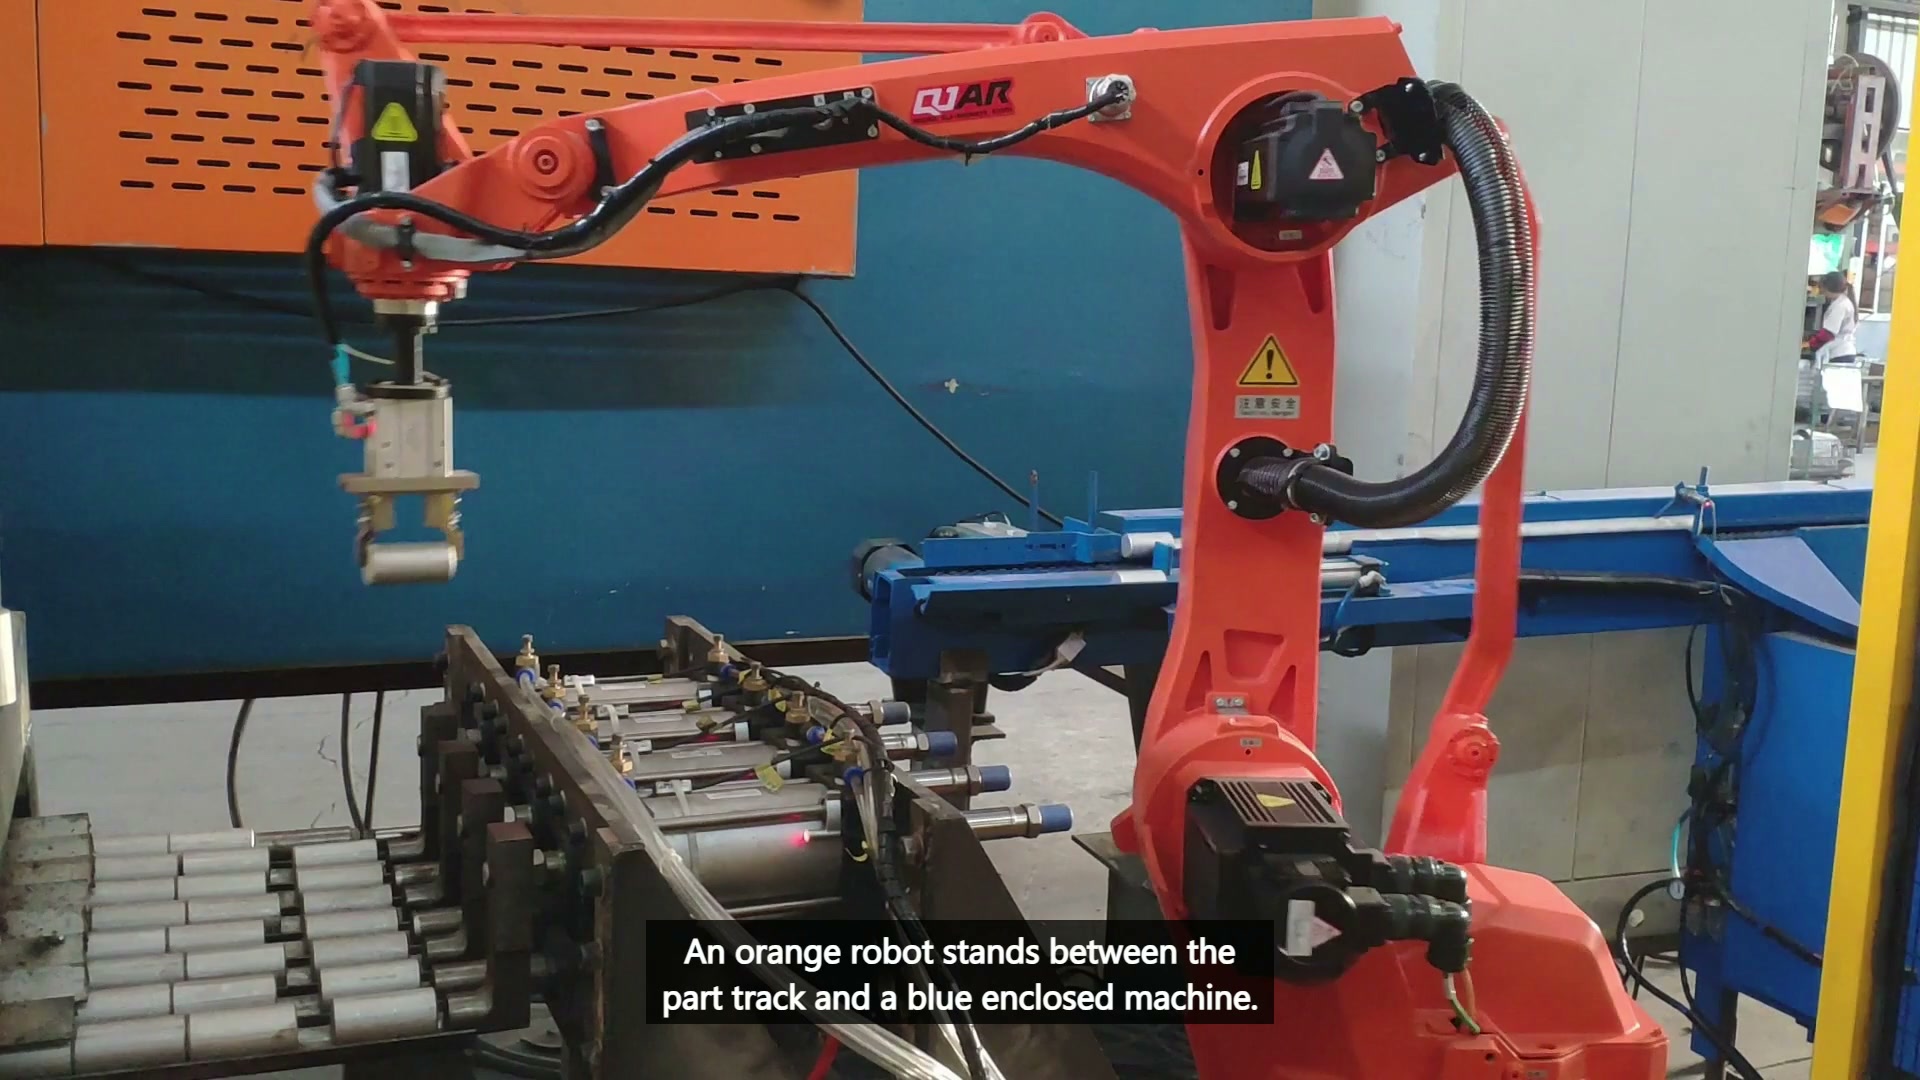
At 00:12.00, the gripper visibly holds one short cylindrical part above the roller-track area.
A round part can roll, rotate or arrive off-center before the jaws close. The support or nest must establish radial position, while an axial stop controls lengthwise location. Jaw contact then has to retain that pose without damaging protected surfaces or pushing the part into a new position. Test the smallest and largest allowed parts and the least favorable surface condition; record empty, partial and skewed grips as well as successful lifts.
The equipment boundary adds a different constraint
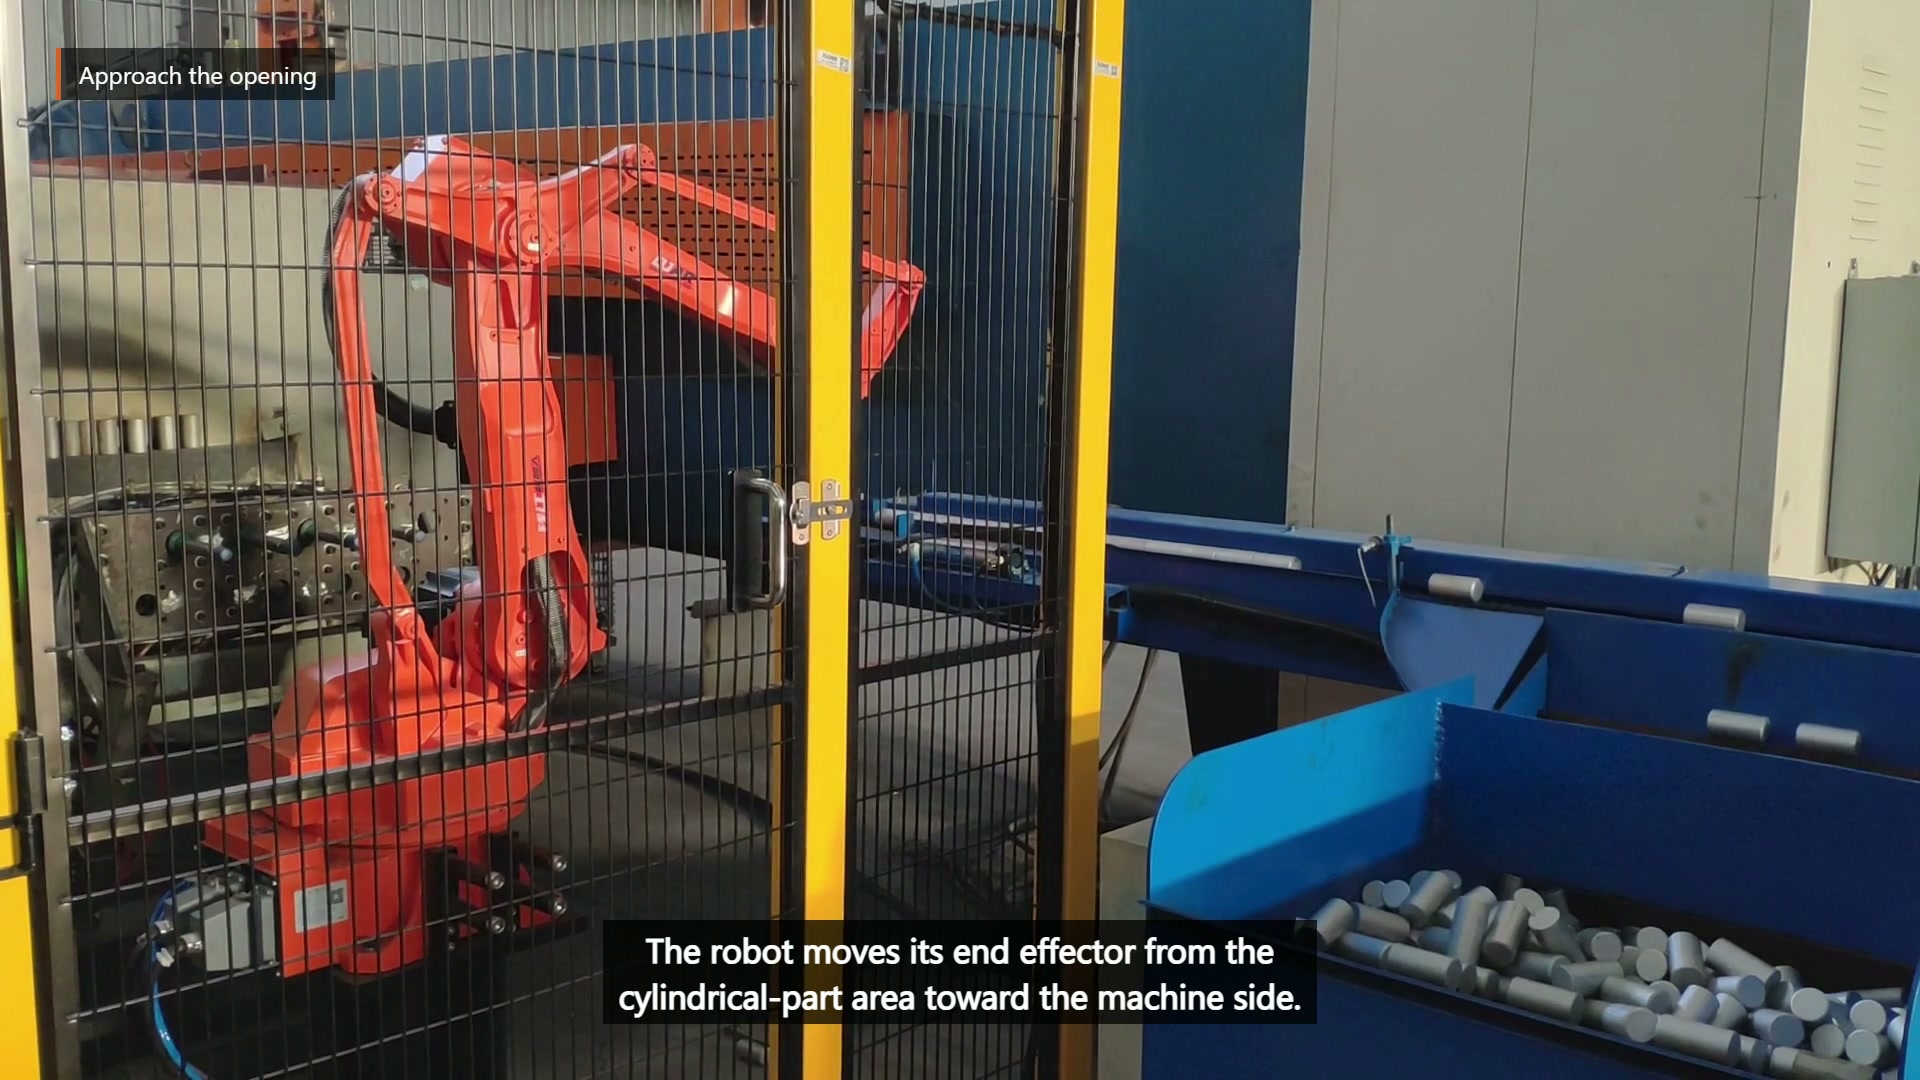
At 00:25.50, the robot moves toward the blue enclosed equipment beside the cylindrical-part area.
Entry depends on an agreed ready state and enough clearance for the gripper, held cylinder and retreat path. A fixed delay cannot prove that internal motion has stopped, access is available or the handoff position is ready. Robot-clear must cover the held part and tool, not only the arm flange.
| Question | Pickup interface | Equipment interface |
|---|---|---|
| What fixes pose? | Radial support and axial stop | Defined handoff location |
| What confirms readiness? | Part present and correctly seated | Access available and receiving state confirmed |
| What volume needs clearance? | Jaw approach around neighboring parts | Tool, cylinder and complete retreat path |
| What failure needs recovery? | Missing, rolling or incomplete grip | Blocked entry, rejected handoff or failure to clear |
The interfaces should be validated separately before they are timed as one cycle. This prevents a stop at the equipment from being misdiagnosed as a gripper problem, or unstable pickup from being hidden by extra clearance downstream.
Recovery tests reveal which interface lost control
Remove a part from the presentation, place one at the worst allowed axial offset, challenge grip confirmation, withhold the equipment-ready state and obstruct the handoff in controlled trials. Each condition needs a safe hold point and a reset route that preserves knowledge of whether the robot is carrying a part.
For a concept review, provide the part drawing, diameter and length range, mass and protected surfaces, presentation support and incoming variation, equipment opening and control states, handoff location, recovery expectations and representative parts. Send these inputs for an EVST concept review → or email sales@evsrobot.com.
The footage supports cylindrical-part handling beside enclosed equipment; final tooling, controls, safeguarding and acceptance depend on project validation.