การลบคมชิ้นส่วนที่ยึดด้วยหุ่นยนต์: ควรแบ่งหน้าสัมผัสและขอบการทำงานอย่างไร?
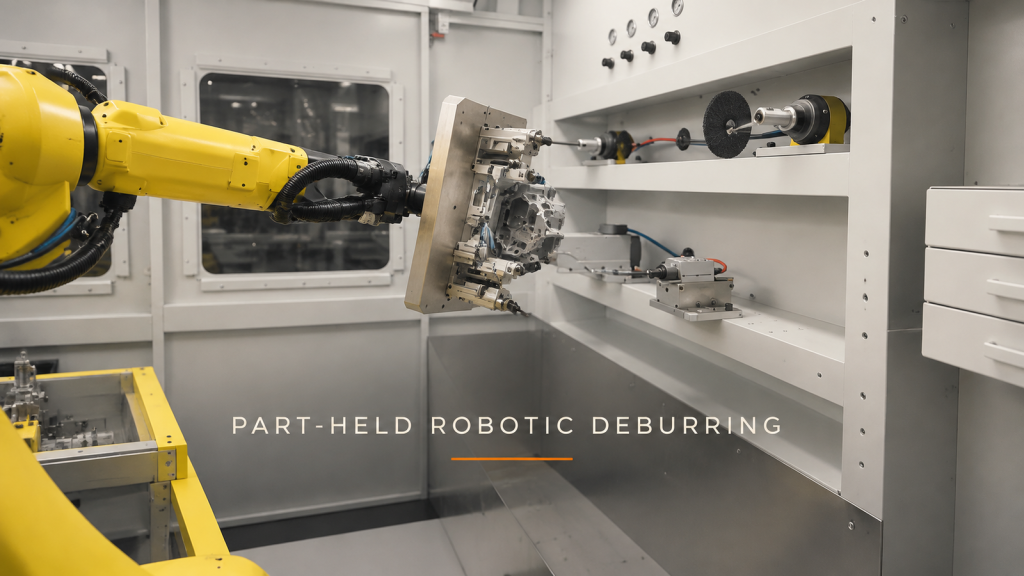
Plan robot-held part deburring by separating gripping faces from working edges, checking fixture clearance and defining each fixed-tool approach.

Plan robot-held part deburring by separating gripping faces from working edges, checking fixture clearance and defining each fixed-tool approach.