
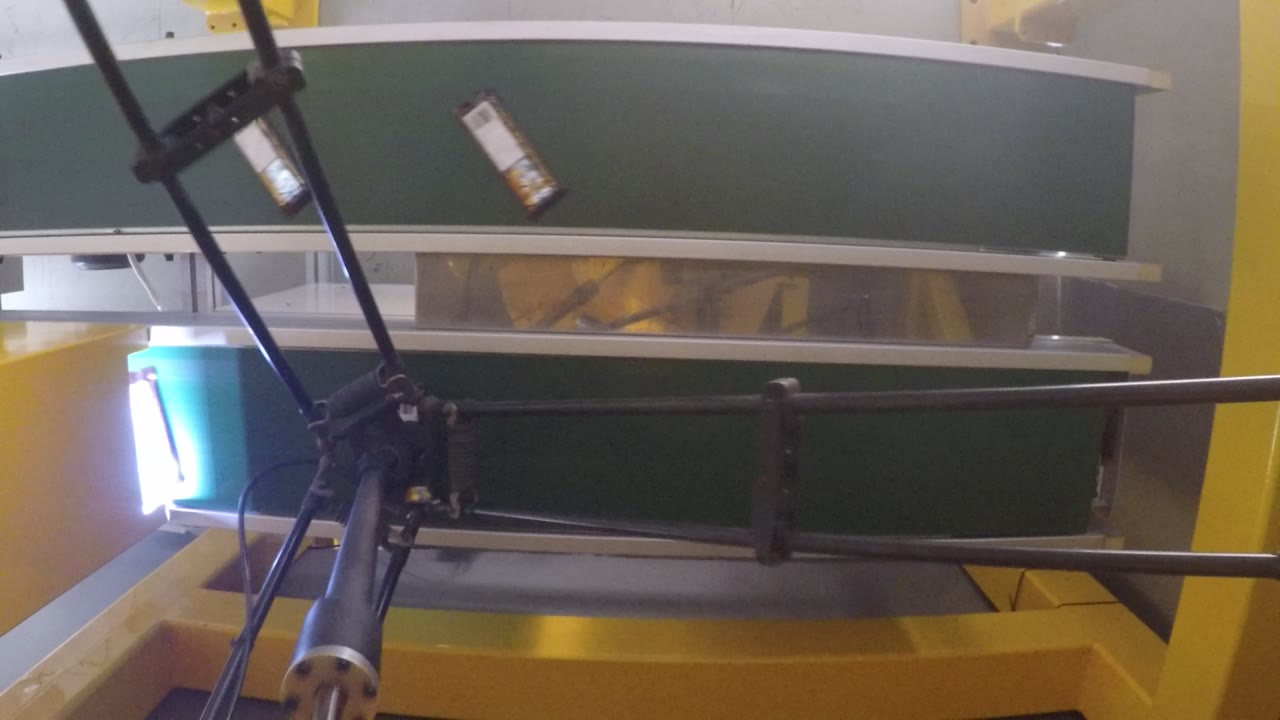
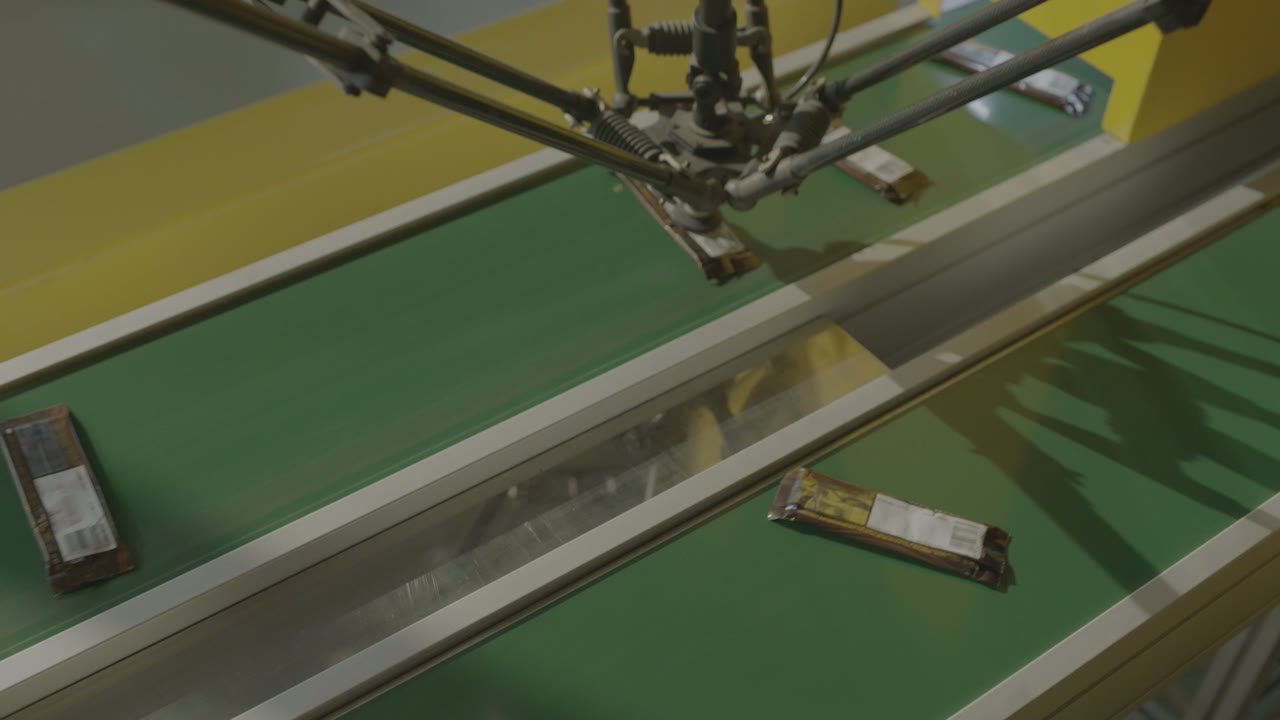
In short: Two conveyors run side by side with a delta robot mounted between them. Wrapped packs arrive loose on one belt — different angles, uneven gaps — and the robot lifts them one at a time and sets them down evenly spaced on the other — the ordered infeed most downstream machines need. The belts never stop. Three decisions carry a cell like this: how the pick head fits the pack, how the arrival pattern matches belt speed, and where exactly each pack has to land. Have a product to line up? Talk to us about your line.
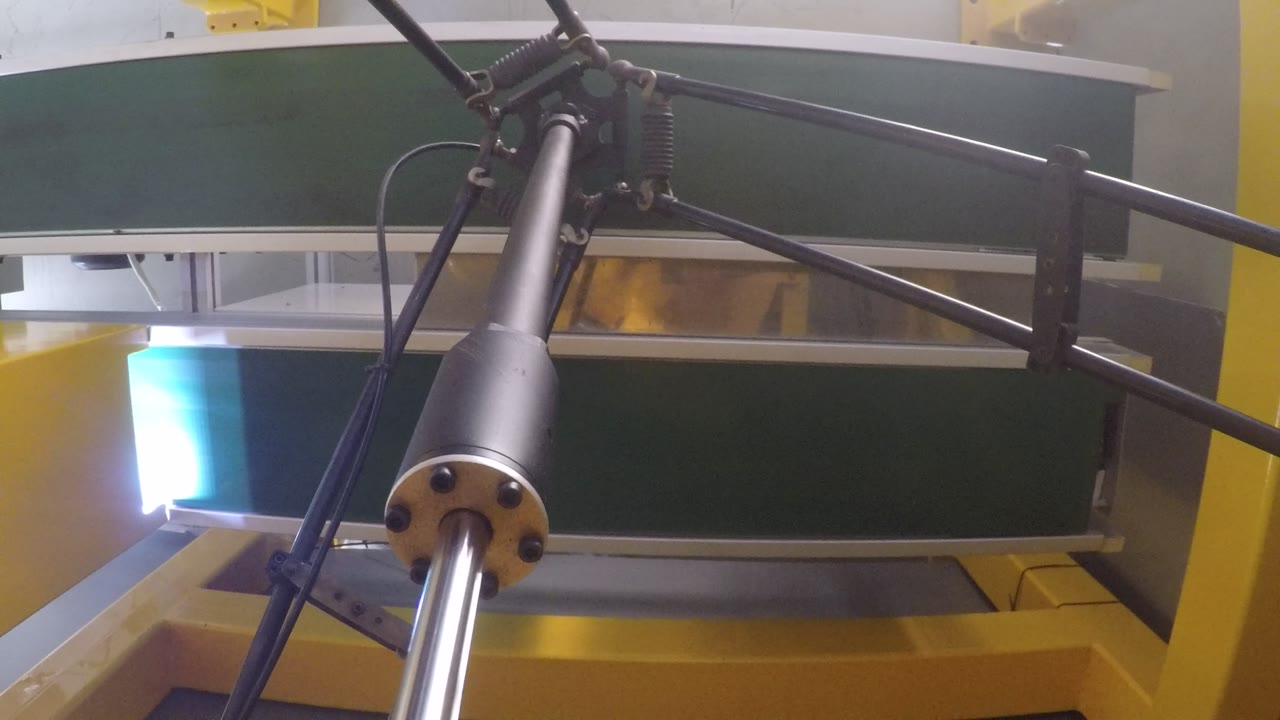
At a glance
| Product | Flat wrapped packs (printed film) |
| Process | Pick and place from a moving belt |
| Automation | One delta robot with a small single-pack pick head |
| Infeed | Packs arrive loose, random angle, uneven spacing |
| Outfeed | Packs placed at even spacing on the second belt |
| Belt motion | Continuous — neither belt stops for the robot |
| Lighting | A light bar runs along the belt edge |
| Operator role | Beside the line, not in the cycle |
The problem this cell addresses
Nearly every packaging line has one point where product comes out of a process in no particular order and has to enter the next machine in a very particular order. Doing that by hand means somebody standing at the belt for the whole shift, matching the belt’s pace instead of their own, touching every single pack.
That job is a good fit for a delta: small payload, short moves, fast repetition, and a task defined entirely by “where is it now, where does it need to be”.
How the cell runs
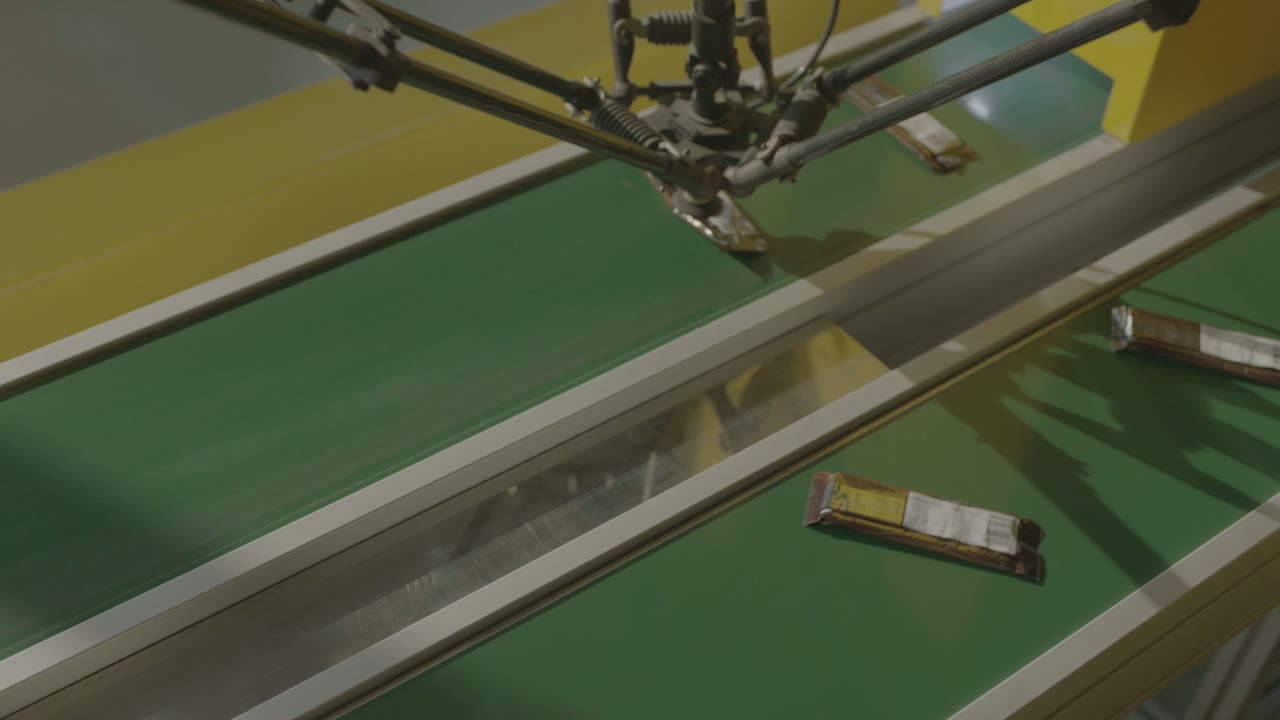
- Arrive. Packs come along the first belt at whatever angle and spacing the upstream process left them in.
- Pass the light bar. A light bar runs along the belt edge; packs show up clearly against the belt as they pass it.
- Pick. The robot drops straight down, takes the pack by its face and lifts.
- Move across. It carries the pack over to the second belt.
- Place. The pack is set down so that packs on the outfeed sit at a far more even spacing than they arrived with.
- Repeat. The belts keep running; the robot takes them as they come.
Three design decisions
1. Fit the tool to the pack, not to the robot
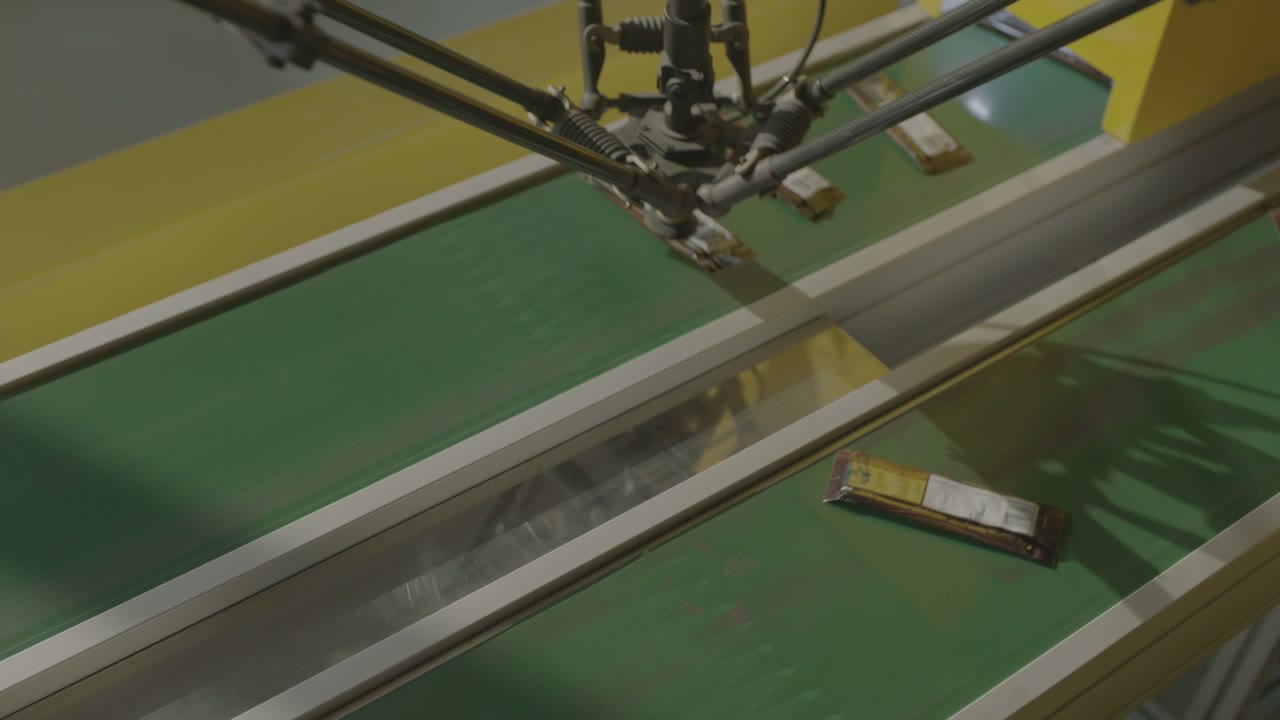
The end tool is where most belt-picking projects succeed or fail. Points worth settling before anything else:
- Where the pack can be touched. Printed film, seams, a soft centre, a product that must not be marked — the usable contact area is often much smaller than the pack.
- How the pack behaves when lifted. Flexible packs bend, and a pack that bends on the way up lands differently than one that does not.
- Release. For vacuum tooling, release is as important as pick: a pack that clings for another few milliseconds lands off-target.
- Food contact. If the tool touches food directly rather than a wrapper, material, cleaning and inspection rules change the design.
Question to settle early: is one pack per cycle the goal, or several? Multi-pack heads raise throughput but only when the arrival pattern makes multi-picks possible.
2. Match arrival spacing to belt speed
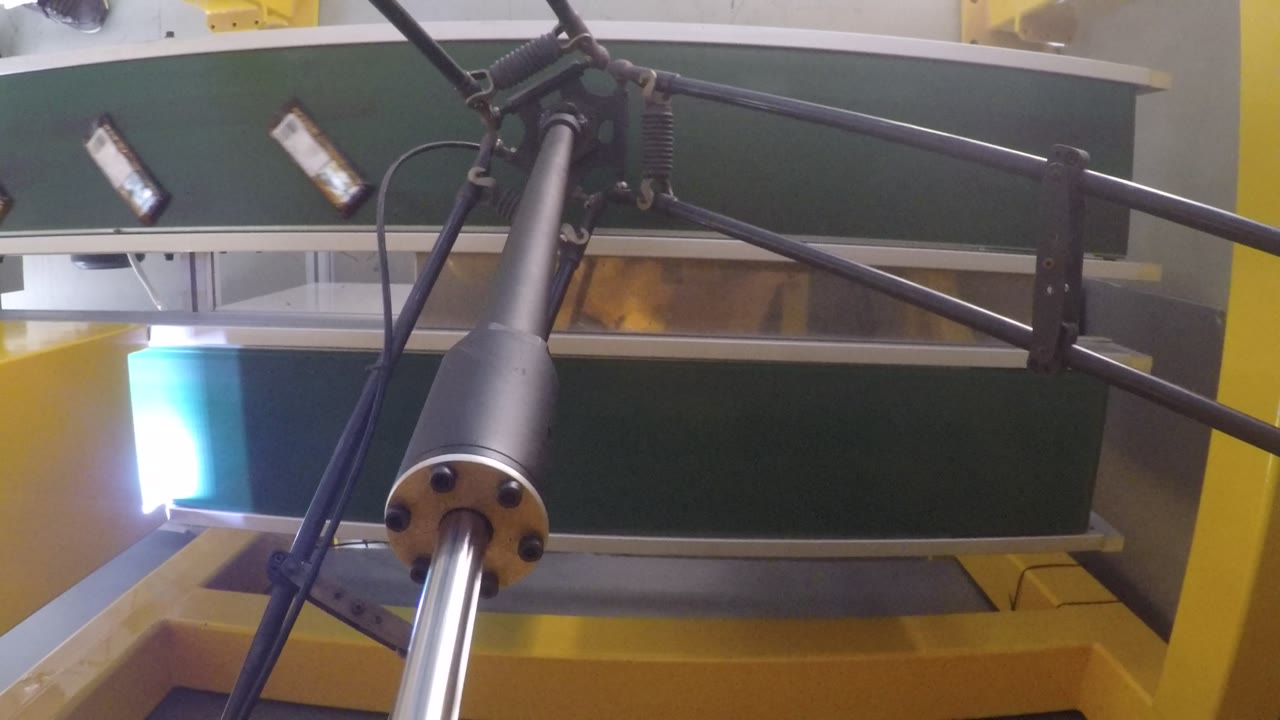
A belt-picking cell is not rated in “picks per minute” alone. What matters is how many packs pass the working window per minute and how many of those the robot can take before they leave it. Three levers:
- Belt speed. Slower means a longer window, but it also means a longer line.
- Density. Too dense and packs overlap or touch, and neither the tool nor the detection can separate them; too sparse and the robot idles.
- Window length. Picking range is set by the robot’s working envelope over the belt, and a second robot in series is the usual answer when one cannot keep up.
Missed picks are normal in a real line; what matters is what happens to them. Decide whether a missed pack recirculates, is caught by a second station, or is removed by hand.
3. Define where the pack has to land
Placement accuracy is defined by the next machine, not by the robot. A cartoner, a flow wrapper and a tray sealer each have their own tolerance for position and angle, and the whole cell should be designed backwards from that number.
- Place against the geometry the next machine actually indexes on — a lug, a flight, a pocket.
- Decide whether the outfeed keeps moving during placement; placing onto a moving belt puts the tolerance into the timing rather than the position.
- Keep the placed pattern regular enough that a downstream jam does not cascade back through the picking window.
When this layout fits — and when to look closer
- Good fit: small, light, repeatable packs; a continuous upstream process; a downstream machine that needs an ordered infeed; and a product that tolerates being handled by a small tool.
- Evaluate further: sticky, dusty or very flexible products; packs that arrive touching each other; high-care hygiene zones (washdown, tool materials); and mixed products where the tool would have to change with the product.
FAQ
One robot or several?
Start from how many packs per minute pass the window and how many one robot can take in that window. When one cannot keep up, two robots in series along the same belt is the usual answer — the second takes what the first leaves.
Does the belt have to stop?
No. In this cell both belts run continuously. Stopping a belt to pick is only sensible on slow lines or for heavy products.
What decides accuracy?
The next machine. Decide its tolerance first, then choose the tool, the placement method and whether the outfeed moves during placement.
Get a layout and cycle-time estimate
Send us:
- Product dimensions, weight and packaging material
- Where the product may be touched, and any hygiene requirements
- Packs per minute in and out, and how the packs arrive (density, orientation)
- What the next machine is and its infeed tolerance
- Line layout and available space over the belts
We will reply with a cell layout proposal and a cycle-time estimate.
Get a layout and cycle-time estimate → or email sales@evsrobot.com
Footage filmed at a partner’s production site. Rate, accuracy and product figures from that site are not public and are not given here.