
Multi-Pass Welding on Medium-Thick Plate: Groove First
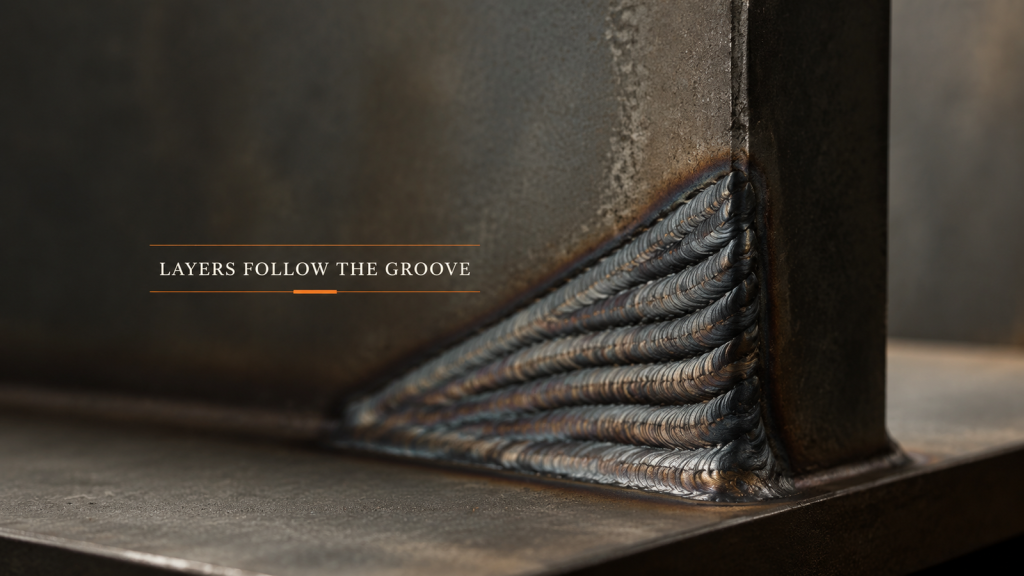
In multi-pass welding the groove sets the cross-section and the cross-section sets the pass count. Plan layers before parameters.
A Robotic Welding Cell Is Six Parts, Not One
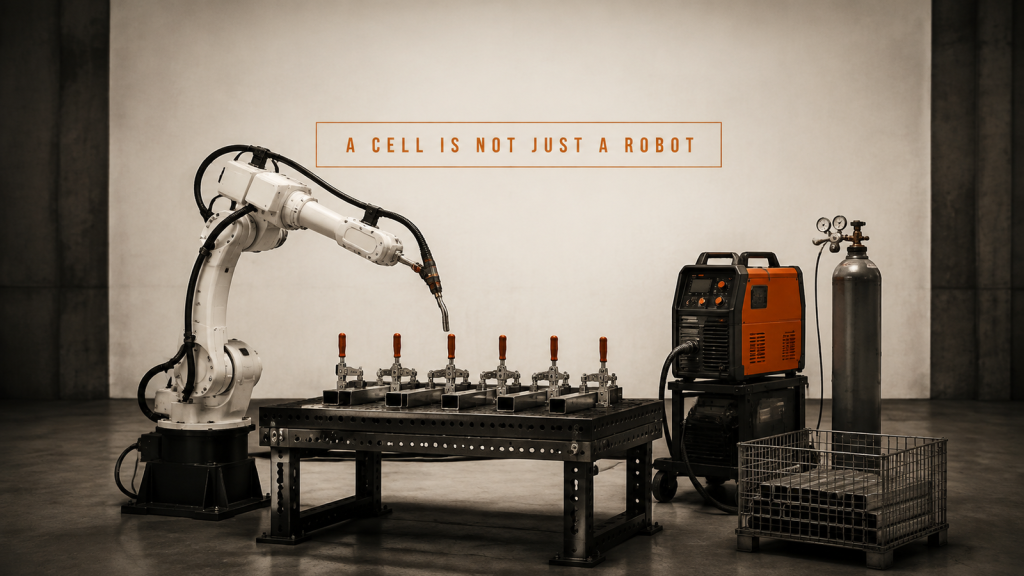
A robotic welding cell is six parts working to one cycle time. Robot and torch, fixture and clamps, power source, gas, loading and flow.
Thin-Sheet Welding: Assembly Gap or Process Parameters?

Separate assembly gap from process parameters on a thin-sheet welding line by starting at the blank and the forming step.
Mobile Welding Platform: Every Stop Is a New Setup

A mobile welding platform still has to re-establish where the part is at every parking position. Site conditions decide repeatability.
Machine Tending Cycle Time Is Not Robot Speed

Machine tending cycle time is set by machine processing, handover sequencing and part staging, not by robot arm speed.
HVAC Duct Manufacturing: Start at the Forming Step

Map rolling, end forming, and changeover before automating HVAC duct manufacturing, because forming decides roundness, fit-up, and line rhythm.
Mobile Welding Robot Planning: Can the Part Stay?

Plan mobile robotic welding from the part, the access route, and the sectioning plan instead of starting from the robot specification.
Automatic Circumferential Seam Welding: Stabilize the Joint

Plan automatic circumferential seam welding around fit-up, clamping, runout, coordinated rotation, torch access, closure, inspection, and restart.
Collaborative Robot Dispensing: Coordinate Path and Flow

Engineer collaborative robot dispensing around part datum, nozzle standoff, path speed, material condition, valve timing, inspection, and recovery.
Robotic Welding and Cutting: Cylinder Path Boundaries

Review robotic welding and cutting on cylinders through supported-profile datums, tool pose, clearance, services, hot-state recovery, and trials.
Automotive Powertrain Automation: Interface Checklist

Plan automotive powertrain automation around inputs, physical state, interfaces, trial evidence, exception routing, and conservative recovery.
SCARA Robot Applications for Fast Pick and Place

Plan SCARA robot applications around inputs, physical state, interfaces, trial evidence, exception routing, and conservative recovery.