
Robot Accessories, Service Parts and Dress Packs
Request model-specific robot motors, servo drives, teach pendants, external-axis and communication cables, cable assemblies, interface boxes, welding torches and consumables, plus dress packs and cable-management parts. Compatibility, condition and supply scope are confirmed against the robot, controller, application, connectors and destination before quotation.
Robot accessory categories available for review
Start with the exact robot brand, model and controller, then identify the required part or assembly. Part numbers, connector photos, cable lengths and application details help separate visually similar components and support a useful compatibility review.
Robot welding torches, consumables and torch cleaning
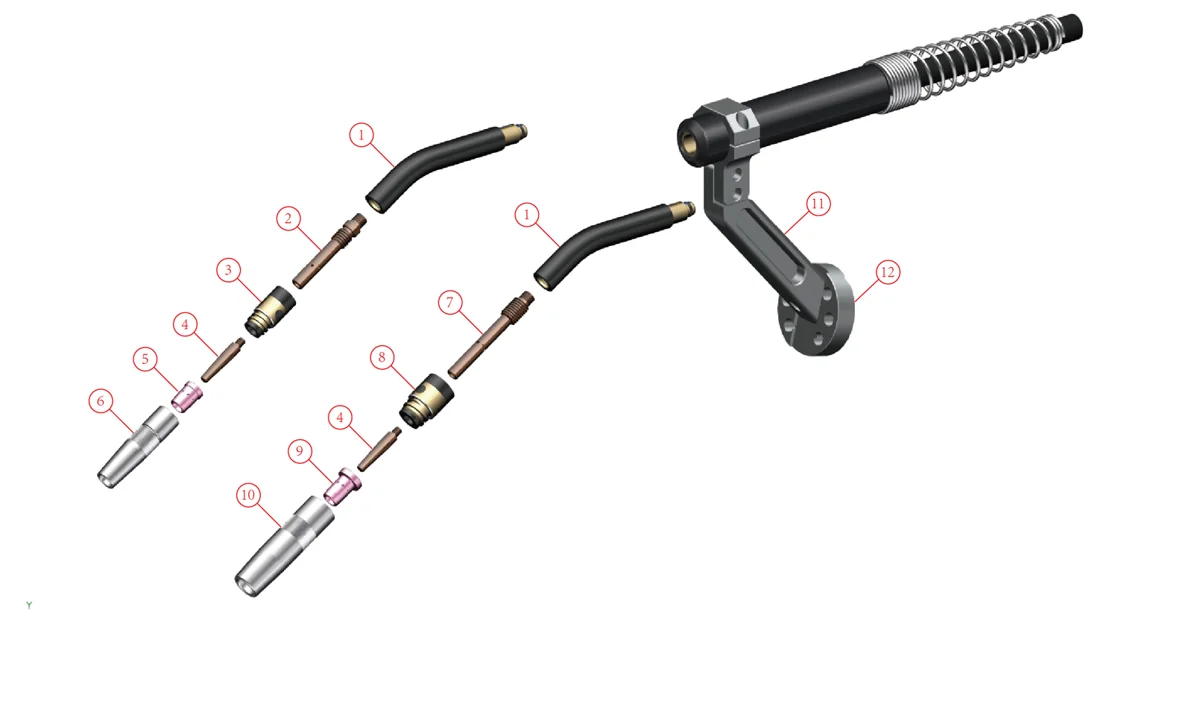
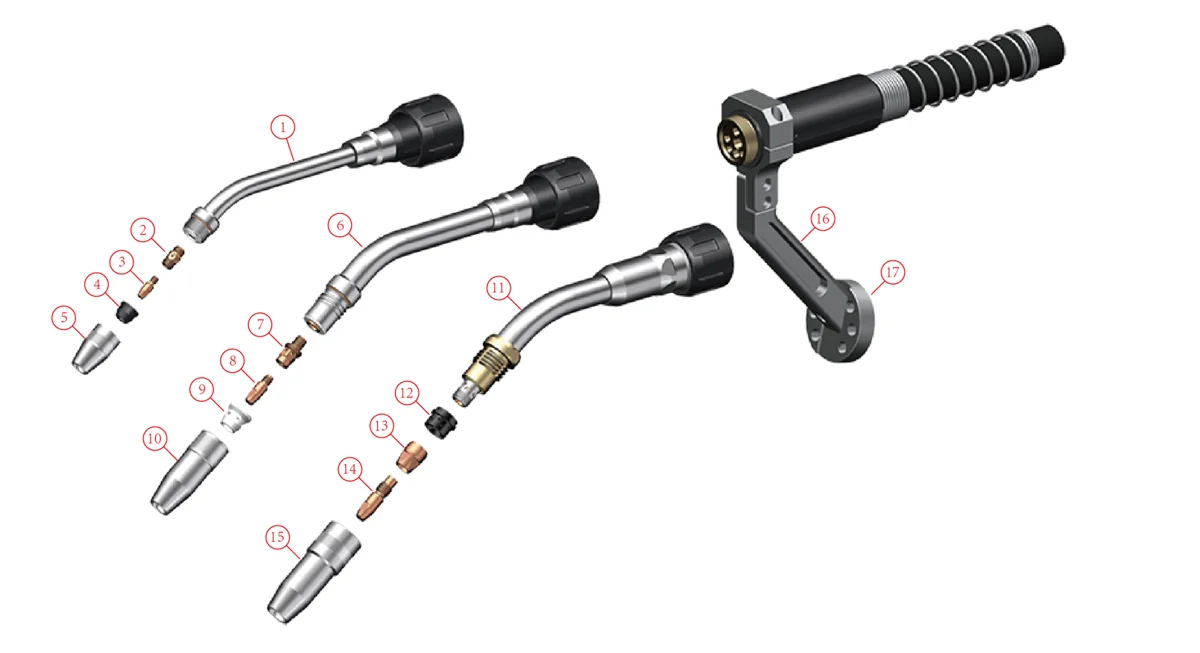
Robotic MIG/MAG welding torches are available for hollow-wrist and external mounting, air-cooled or water-cooled, with collision sensors, cable assemblies, wear parts and torch-cleaning equipment. OEM or compatible options can be quoted on request; the torch class, mounting, cable length and wire-feeder connection are confirmed against the robot and welding process before quotation.
Robotic MIG/MAG torch ratings
| Torch class | Cooling | Mounting | Rated current (MIG) | Rated current (MAG) | Duty cycle | Wire diameter |
|---|---|---|---|---|---|---|
| 150 A narrow | Air | Hollow-wrist or external | 150 A | 100 A | 60% | 0.8–1.0 mm |
| 300 A narrow | Air | Hollow-wrist or external | 300 A | 250 A | 60% | 0.8–1.2 mm |
| 350 A | Air | Hollow-wrist or external | 350 A | 300 A | 60% | 0.6–1.2 mm |
| 430 A | Air | Hollow-wrist | 430 A | 380 A | 50% | 0.8–1.2 mm |
| 500 A | Air | Hollow-wrist or external | 500 A | 400 A | 50% | 1.2–1.6 mm |
| 300 A | Water | Hollow-wrist or external | 300 A | 250 A | 100% | 0.8–1.2 mm |
| 500 A | Water | Hollow-wrist or external | 500 A | 450 A | 100% | 0.8–1.6 mm |
| 650 A | Water | Hollow-wrist or external | 650 A | 600 A | 100% | 0.8–1.6 mm |
| 500 A push-pull | Water | External | 500 A | 450 A | 100% | 0.8–1.6 mm |
A water-cooled robotic TIG torch rated 400 A at 80% duty cycle is also available, with an automatic wire-feed frame for 0.8–1.2 mm filler wire.
Consumables by torch class
| Torch class | Neck angles | Contact tip | Tip holder | Nozzle |
|---|---|---|---|---|
| 350 A air | Straight, 22°, 31°, 35°, 36°, 45° (by series) | M6 × 45 mm, CuCrZr; for 0.8, 1.0, 1.2 and 1.6 mm wire; aluminium-wire versions | CuCrZr, M10 × M6, 74.5 mm | Ø20 × 73 mm; bore 13 or 16 mm |
| 500 A air | Straight, 22°, 31°, 35°, 36°, 45° (by series) | M6 × 45 mm, CuCrZr; for 0.8, 1.0, 1.2 and 1.6 mm wire; aluminium-wire versions | CuCrZr, M10 × M6, 88.5 mm | Ø25 × 88 mm; bore 16 or 19 mm |
| 430 A air | Straight, 22°, 36°, 45° | M8 × 35 mm, CuCrZr; for 0.8, 1.0, 1.2 and 1.6 mm wire; aluminium-wire versions | Brass, M8, 43 mm | 70 mm long; bore 13 or 16 mm |
| 150 A narrow air | 45° | M6 × 13 mm, CuCrZr; for 0.8, 1.0, 1.2 and 1.6 mm wire | Copper, M6 × M6, 18 mm | Ø18 × 30 mm; bore 13 mm |
| 300 A narrow air | 45° | M6 × 28 mm, CuCrZr; for 0.8, 1.0, 1.2 and 1.6 mm wire | Copper, M10-1 × M6, 38.5 mm | Ø24 × 44.5 mm |
| 300 A water | Straight, 22°, 36°, 45° | M6 × 22 mm, CuCrZr; for 0.8, 1.0 and 1.2 mm wire; aluminium-wire versions | CuCrZr, M10-1 × M6, 20 mm | Ø25 × 40 mm; bore 11, 13 or 15 mm |
| 500 A water | Straight, 22°, 36°, 45° | M8 × 30 mm, CuCrZr; for 1.0, 1.2 and 1.6 mm wire; aluminium-wire versions | CuCrZr, M10-1.25 × M8, 29 mm | Ø28 × 73.5 mm; bore 15, 18 or 21 mm |
| 650 A water | Straight, 22°, 36°, 45° | M12 × 45 mm, CuCrZr; for 1.2, 1.4, 1.6 and 2.0 mm wire; aluminium-wire versions | CuCrZr, M16-1 × M12, 23 mm | Ø30 mm; bore 18 or 21.5 mm |
Gas diffusers, insulating sleeves and custom goosenecks made to drawing are also available. Longer necks change the torch TCP, so the neck length and angle are confirmed with the robot program in mind.
Collision sensors
Collision (shock) sensors stop the robot when the torch hits the workpiece or fixture and then reset to position. The data below is stated per IEC 60974-7. All listed sensors reset the TCP to within ±0.2 mm laterally, measured 300 mm from the flange, and hollow-wrist sensors allow rotation of ±220° from the zero position. Versions with an integrated wire brake are available.
| Sensor for | Maximum deflection | Emergency-stop trigger (X and Y plane) |
|---|---|---|
| Hollow-wrist, air-cooled (type 1) | 11° | 1.3° |
| Hollow-wrist, air-cooled (type 2) | 17° | 3° |
| Hollow-wrist, air-cooled (type 3) | 13° | 3.5° |
| Hollow-wrist, water-cooled | 11° | 1.3° |
| External, air-cooled (type 1) | 17° | 3° |
| External, air-cooled (type 2) | 13° | 3.5° |
| External, water-cooled | 10° | 1.2°–1.5° |
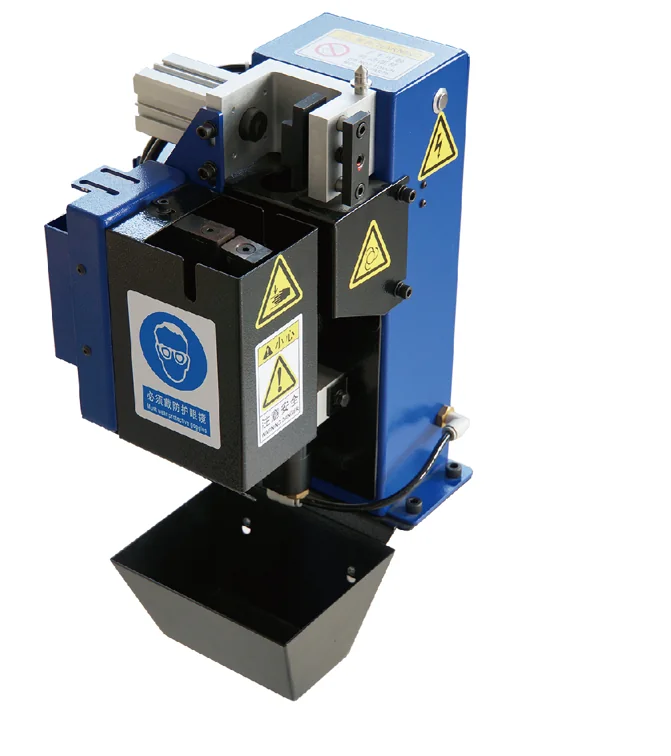
Torch cleaning station with wire cutter
| Parameter | Value |
|---|---|
| Compressed air | G1/4" inlet; hose inside diameter at least 6 mm; nominal 6 bar, operating 6–8 bar |
| Air consumption | Approx. 400 L/min |
| Pneumatic motor speed | Approx. 650 rpm |
| Control signal | NPN (0 V DC) or PNP (24 V DC) |
| Operating voltage | 10–30 V DC; valve power 2.8 W |
| Wire cutting | Solid wire up to 1.2 mm at 6 bar; cutting time 1 s |
| Anti-spatter bottle | 500 ml |
| Stand | 700 mm high; base plate 240 × 240 mm |
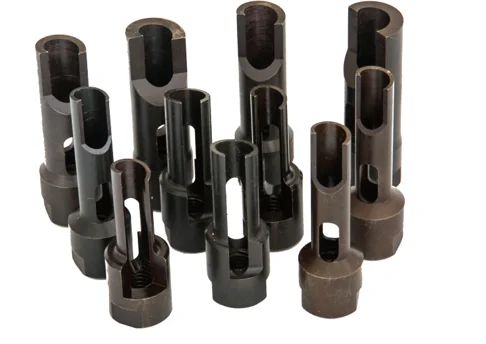
Reamers are sized to the torch: the reamer inside diameter is the contact-tip outside diameter plus 1 mm, and the reamer outside diameter is the nozzle inside diameter minus 1 mm. Water-based anti-spatter liquid is supplied for steel, stainless steel and aluminium welding.
What to send for a torch or consumables quote
- Robot brand and model, and whether the torch cable runs through a hollow wrist or is mounted externally.
- Welding process, current and duty cycle, and whether air or water cooling is needed.
- Wire type and diameter, including aluminium wire if used.
- Wire-feeder connection, for example Euro, Panasonic, OTC or Lincoln.
- Cable length. For a hollow-wrist robot, measure from the axis-6 flange face to the axis-5 centre, from the axis-5 centre to the end face of the axis-3 hole, and from there to the wire-feeder adaptor. For an external torch, measure from the axis-6 flange face to the axis-5 centre and from the axis-5 centre to the wire-feeder adaptor.
- Neck angle and length, collision sensor or wire-brake requirements, and consumable quantities.
Robot dress packs
A robot dress pack bundles the cables and hoses running from the base to the tool into a protective corrugated hose, fixed and guided along the arm by brackets, clamps and anti-collision rings, with an optional spring retraction system that keeps the hose tight as the wrist moves. Dress packs can be supplied as empty kits or configured around a customer cable and hose list. Hose sizes are 36 mm for compact and collaborative robots, and 48 mm or 70 mm for industrial robots; the run can be continuous from axis 1 to axis 6 (A1–A6) or divided at axis 3 (A1–A3–A6).
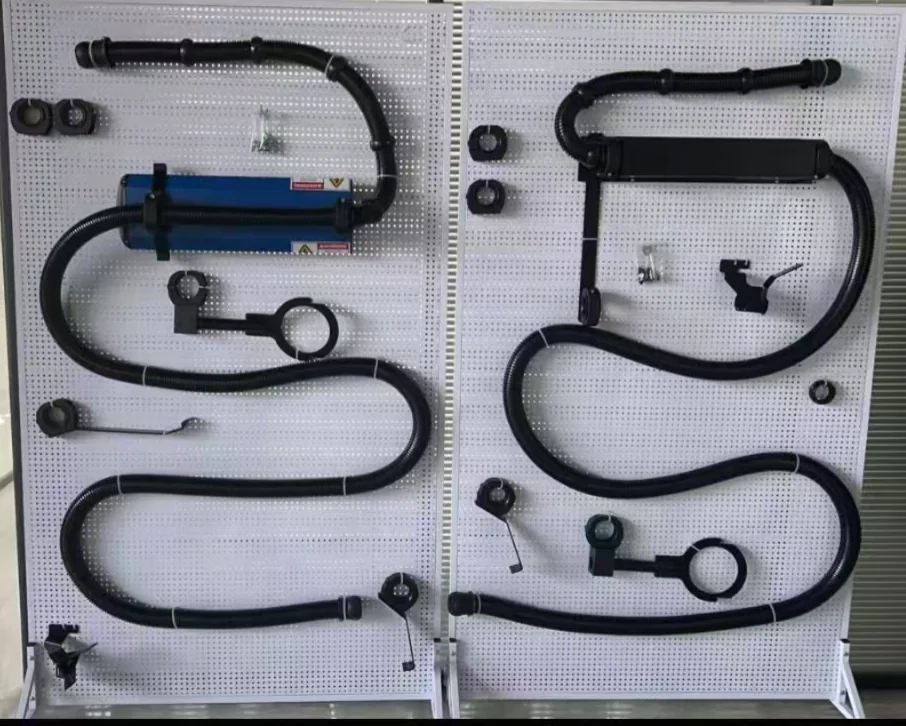
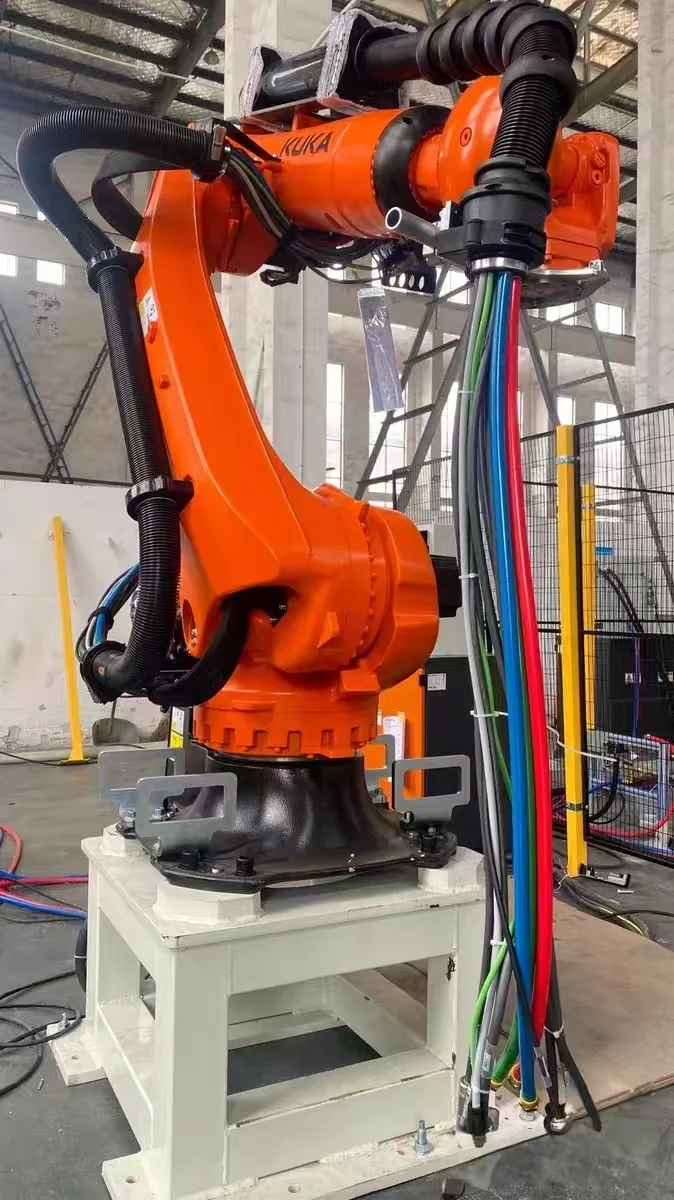
Reference dress pack configurations
| Robot brand | Robot model | Hose | Routing | Spring retraction |
|---|---|---|---|---|
| KUKA | KR 4 R600 | 36 mm | A1–A6 | Without |
| KUKA | KR 20 R1810-2, KR 70 R2100, KR 210 R2700-2, KR 360 R2830 | 48 mm 70 mm | A1–A6 A1–A3–A6 | With or without With |
| ABB | IRB 6700-200/2.60 | 48 mm 70 mm | A1–A6 A1–A3–A6 | With or without With |
| FANUC | R-2000iC/210F | 48 mm 70 mm | A1–A6 A1–A3–A6 | With or without With |
| Yaskawa | GP180 | 48 mm 70 mm | A1–A6 A1–A3–A6 | With or without With |
| FANUC, Universal Robots, AUBO | CRX-10iA, UR10, i5 (collaborative) | 36 mm | A1–A6 | Without |
Reference configurations are supplied as empty dress packs and can be customised; the final design is confirmed against the exact robot variant, process media and working poses.
More accessory categories being added
Detailed data for further categories, including robot motors, servo drives, teach pendants, external-axis and communication cables and interface boxes, is being prepared for this page. Requests for these parts can already be reviewed: send the robot and controller model, the part name or number and connector photos using the accessory compatibility request above.
Robot accessories FAQ
What robot accessory and spare-part categories can EVST review?
EVST can review requests for brand-specific robot motors, servo drives, teach pendants, external-axis and communication cables, cable assemblies, interface boxes, welding torches, goosenecks, contact tips, gas diffusers or tip holders, nozzles, wire cutters, dress packs and cable-management parts. Exact compatibility, condition and availability are confirmed for each request.
What is a robot dress pack and why is cable and hose management important?
A robot dress pack routes and protects the electrical cables, pneumatic lines and process hoses that move with the robot. Correct routing helps control bending, twisting, abrasion, snagging and collision risk throughout the required motion while keeping inspection and maintenance practical.
How is a robot dress pack selected for cable and hose routing?
Selection starts with the exact robot and process, then checks cable and hose types, connector locations, wrist motion, bend radius, retraction, collision clearance, mounting, environment and maintenance access. Robot brand alone is not enough to define the routing package.
What information is required for robot accessory compatibility review?
Provide the robot brand, exact model and controller, mounting orientation, process, tooling, working poses, interface and media requirements, environment, quantity and destination. Photos or layout drawings can help when routing or clearance is critical.
Can accessories be reviewed with the complete robot automation project?
Yes. The review can coordinate the robot, dress pack, tooling, process equipment, controls, safety, cell layout, commissioning and service requirements so accessory choices are checked against the complete motion and system scope.
What should I provide for a robot dress pack or accessory quote?
Provide the robot brand and exact model, controller, application, carried media, cable and hose specifications, connector points, mounting and working poses, environment, quantity, destination and requested timing. Layout drawings or motion information are useful when routing and clearance affect the configuration.
How do I choose a robotic MIG/MAG torch class and cooling?
Start from the welding current and duty cycle. Air-cooled robotic torches in the table above are rated from 150 A to 500 A at 50–60% duty cycle; water-cooled torches are rated 300 A to 650 A at 100% duty cycle and suit long arc-on times or high currents. Then choose hollow-wrist or external mounting to match the robot, and check the wire diameter range of each class.
How is the cable length for a robot welding torch measured?
For a hollow-wrist robot, measure three sections: from the axis-6 flange face to the axis-5 centre, from the axis-5 centre to the end face of the axis-3 hole, and from there to the wire-feeder adaptor. For an externally mounted torch, measure from the axis-6 flange face to the axis-5 centre and from the axis-5 centre to the wire-feeder adaptor.
Are OEM or compatible robot torch consumables available?
Both can be quoted. Contact tips, tip holders, nozzles, gas diffusers and necks are matched to the torch class, thread and wire diameter, so send the torch model or photos of the existing parts together with the wire type and quantities.
What do 48 mm, 70 mm and A1–A3–A6 mean in a robot dress pack specification?
The millimetre value is the corrugated hose size: 36 mm is common on compact and collaborative robots, 48 mm and 70 mm on industrial robots, depending on how many cables and hoses the pack carries. A1–A6 is one continuous run from axis 1 to axis 6; A1–A3–A6 divides the run at axis 3 into two sections.
Author: EVST Editorial Team
The EVST Editorial Team maintains this page to support robot selection and project planning. Product availability, configuration, safety validation and integration scope must be confirmed for the actual application.
Editorial policy · Corrections policy · Terms of use
Last updated: