Gratowanie części przy użyciu robota: Jak podzielić powierzchnie chwytające i krawędzie robocze?
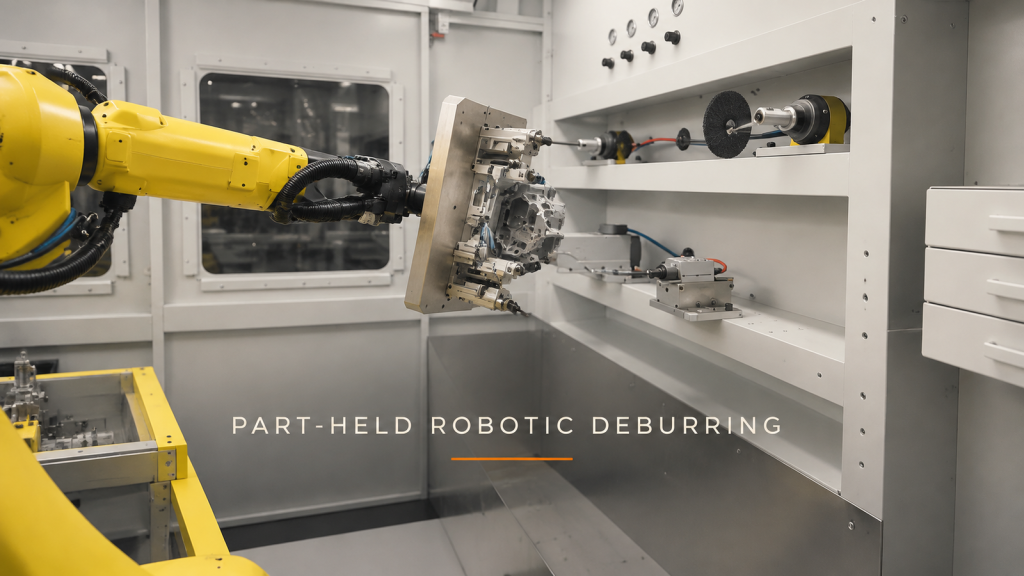
Plan robot-held part deburring by separating gripping faces from working edges, checking fixture clearance and defining each fixed-tool approach.

Plan robot-held part deburring by separating gripping faces from working edges, checking fixture clearance and defining each fixed-tool approach.