
A fixture can hold a cylinder-and-bracket assembly securely and still make it difficult to weld robotically. Before committing to a cell layout, test two things together: whether representative assemblies put the joint in a repeatable position, and whether the whole torch can enter, follow and leave that joint. A firm clamp alone answers neither question.
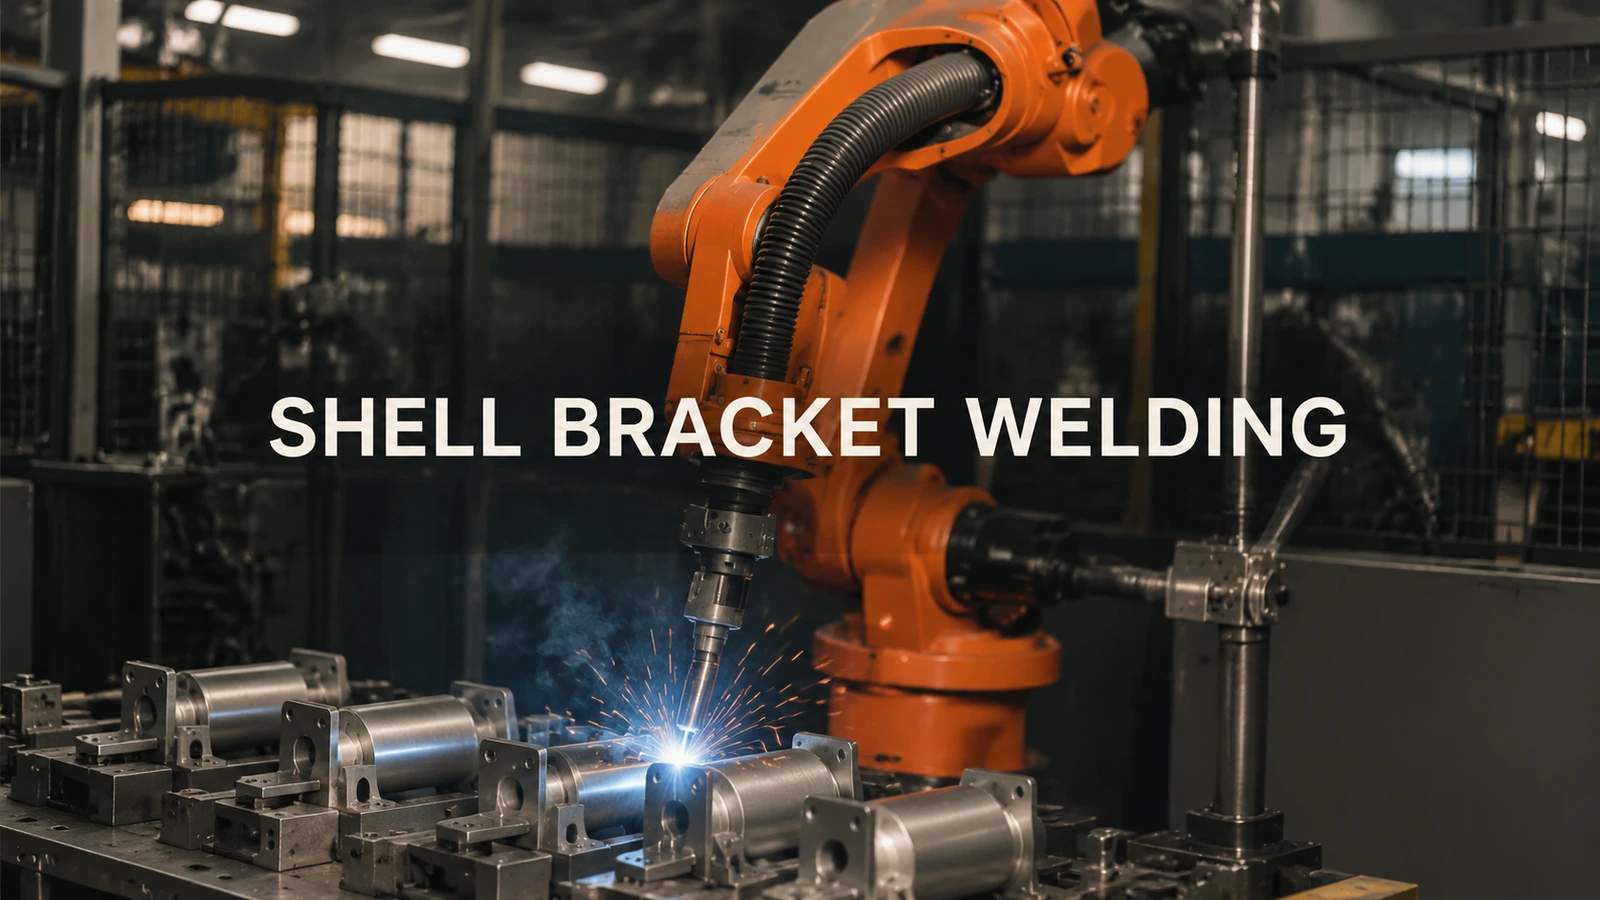
When the part is stable but the joint moves
Start with the joint rather than the outside of the cylinder. If the bracket seats differently against successive shells, a repeatable clamp position may still leave a changing joint location or gap. Treat this as an assembly investigation before asking the robot to compensate.
For a trial, bring parts that represent the variation you actually receive. Load them using the intended locating surfaces and record where the joint changes. Then separate the causes: variation in the shell, variation in the bracket, or variation introduced while loading and clamping. This proposed comparison is useful when those causes have not yet been distinguished; it is not a tolerance specification.
Robot-welding guidance identifies repeatable parts, fit-up and joint access as selection issues. That supports evaluating the assembly and tool route together, rather than treating nominal robot positioning as the entire welding problem.
A clamp can occupy the space the gun needs
The filmed example shows a robot welding around a cylindrical shell and bracket held in a fixture. It provides a useful view of the relationship between the workpiece, support and torch. The buying question is how that relationship behaves across the intended parts and weld locations.
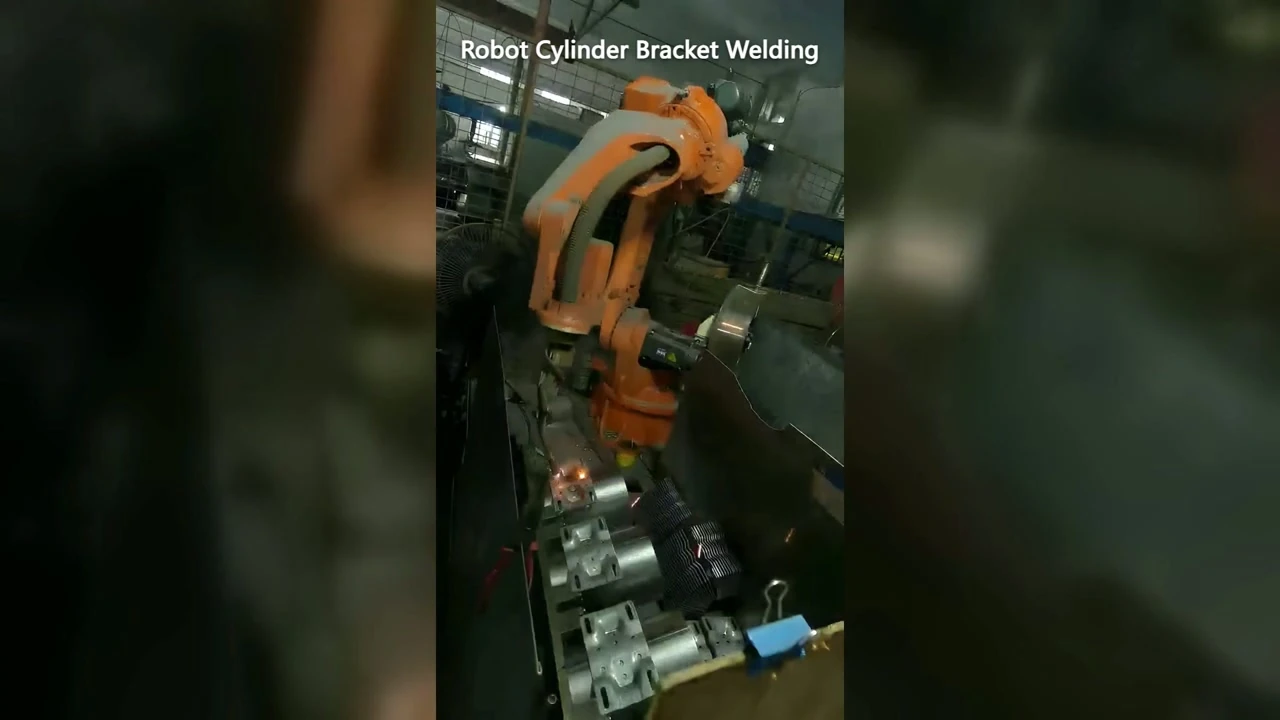
00:08 — Torch beside the fixtured cylinder-and-bracket assembly.
Check the complete tool envelope, not just the tip at the first point. A path may begin with ample space and become constrained as the torch changes direction. Include the approach and withdrawal in the trial, and review whether a clamp or support blocks the required orientation. A trial that checks only the weld start can miss the conflict later in the path.
Where access is restricted, compare relocating a clamp, changing the loading orientation or revising the fixture arrangement before freezing the mechanical design. Each option should retain the locating function the assembly needs. Removing an obstruction by removing necessary support simply exchanges one problem for another.
Make the trial produce a fixture decision
Ask the trial team to return marked-up joint locations and the specific positions where the tool or fixture needs a change. Keep the part-loading method with that record. Otherwise a successful demonstration can depend on careful manual positioning that is absent from the proposed production method.
The useful outcome is a decision about what must become repeatable and what space must remain open. Weld acceptance should then be assessed against the agreed joint requirements; a collision-free motion is only one part of that assessment.
Share assembly photos, weld-joint locations and the available fixture space with EVST. These inputs can support a discussion of robotic welding layout and the fixture risks worth testing first.